Takuya Kiyokawa

What makes a task difficult for a robot?

I study how preparation can make robotic manipulation easier in the real world.

Portfolio

Research projects

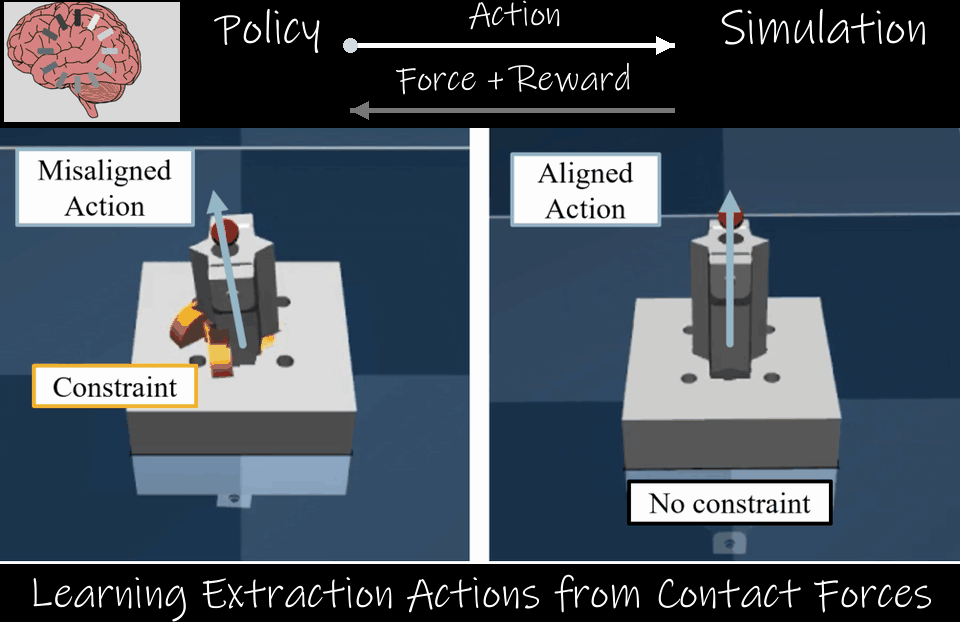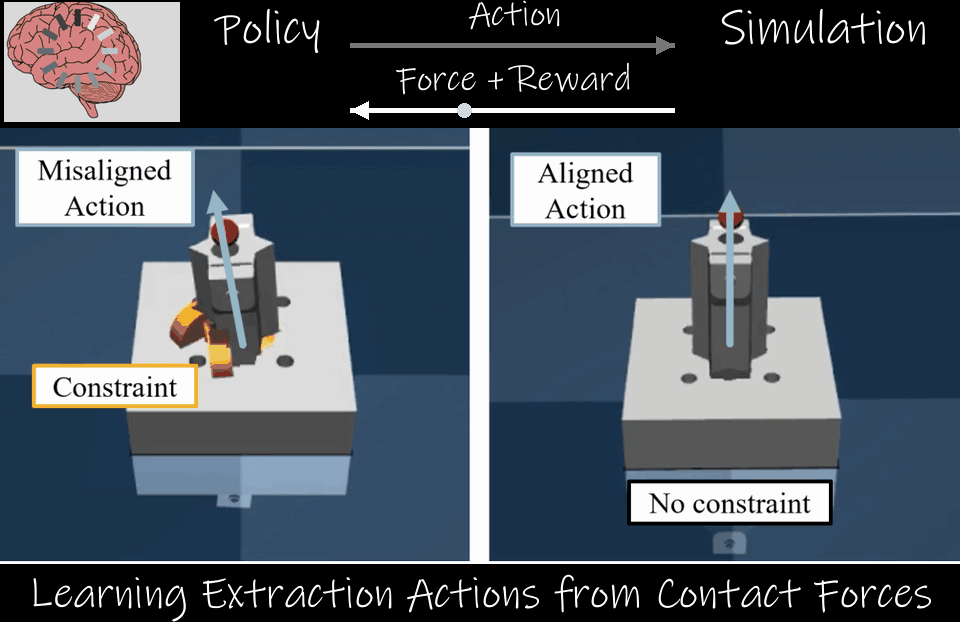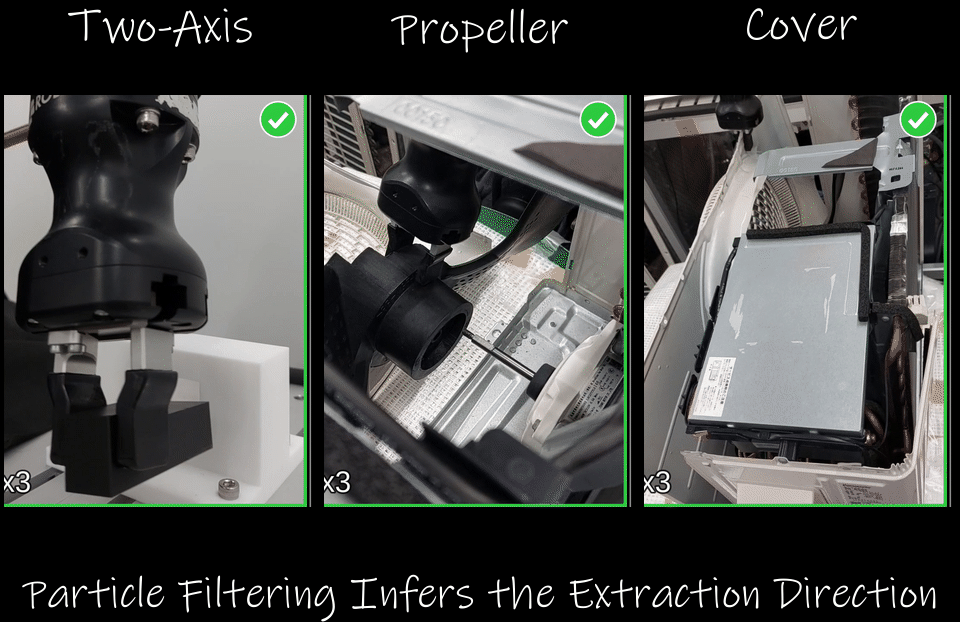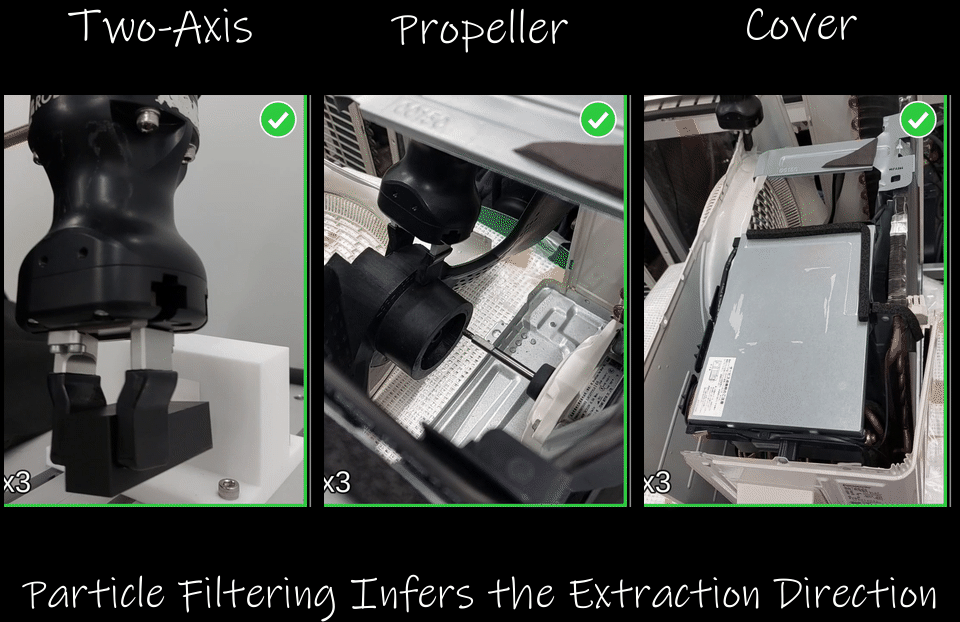
Zero-Shot RL Disassembly

Zero-Shot RL Disassembly

A particle filter processes contact-force history to estimate candidate extraction directions, which inform the learned policy’s next action. Trained in simulation and deployed without further learning, the policy disassembles unseen mating parts and air-conditioner components without product-specific models or demonstrations.

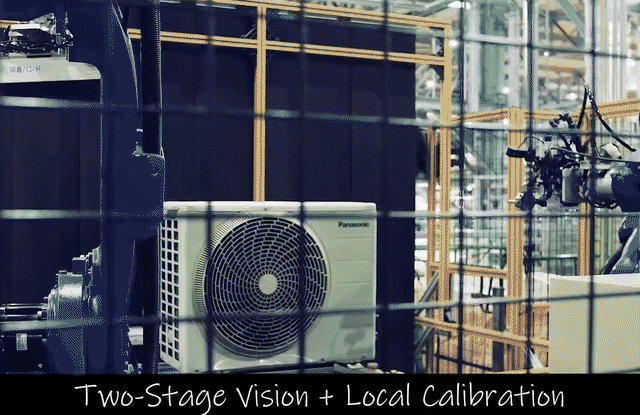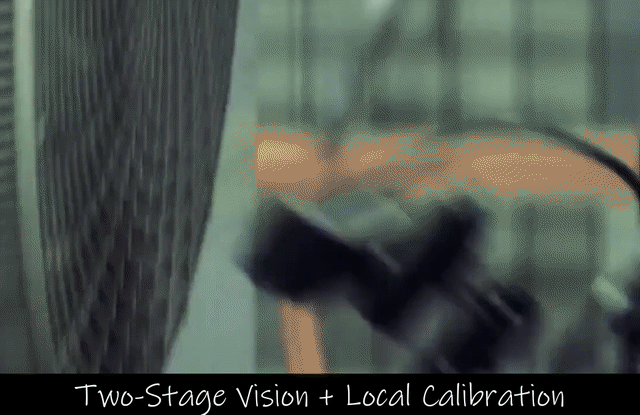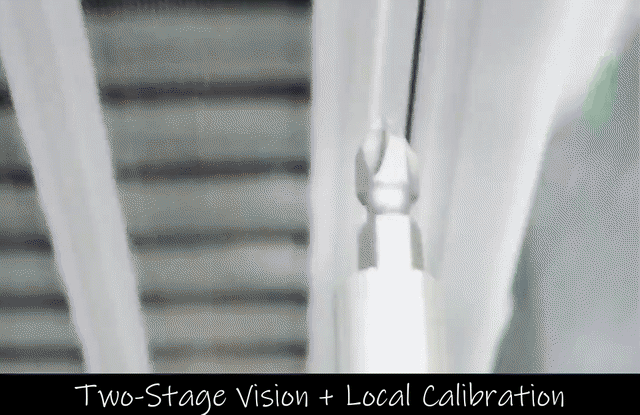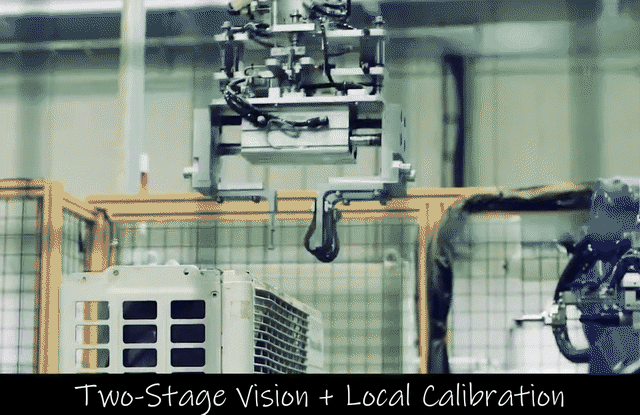
Two-Stage Vision for Screw Removal

Two-Stage Vision for Screw Removal

Two-stage detection extracts screw candidates with high recall, then rechecks them with multiple learned models. Head and cross-slot features locate the center. Local interpolation of measured camera-to-robot coordinate correspondences improves positioning, achieving 99.8% recall and ±0.75 mm accuracy despite dirt and rust.

Enveloping Grasp Teleoperation

Enveloping Grasp Teleoperation

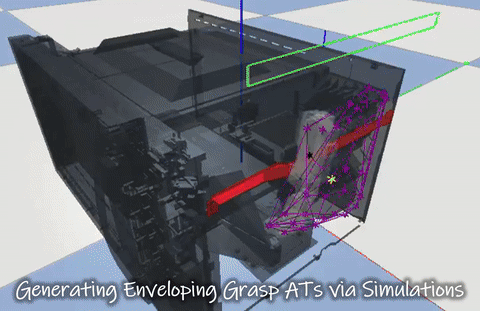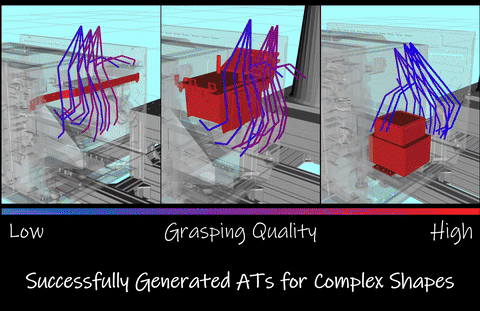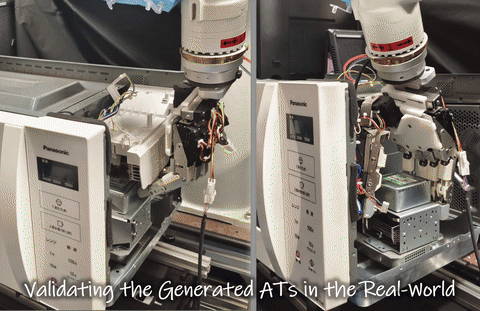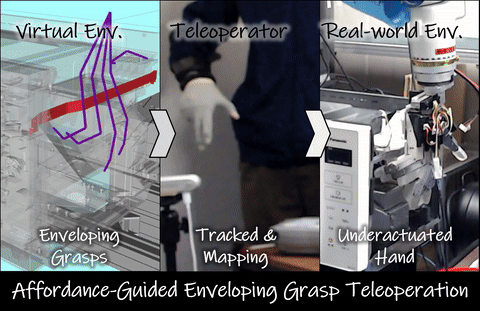
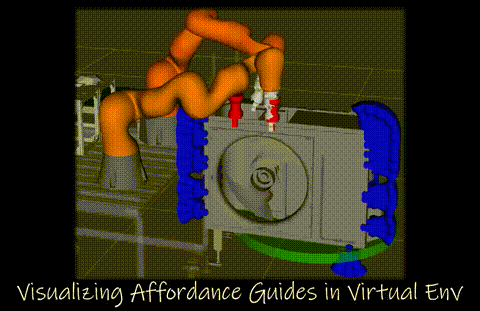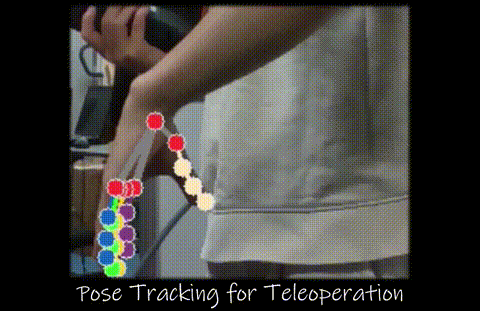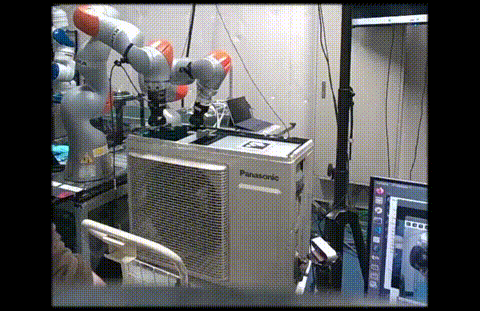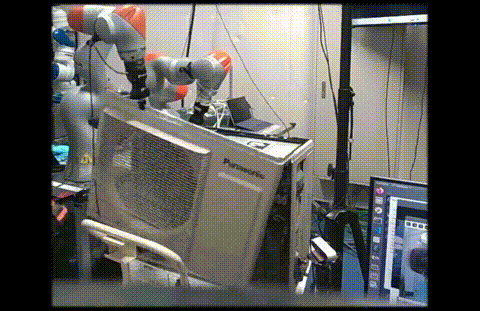
Affordance-guided teleoperation supports enveloping grasp demonstration for non-destructive disassembly of pinch-infeasible mating parts. Physics simulation generates grasp candidates, while color gradients visualize grasp quality to help operators teach grasps under visual and geometric constraints.

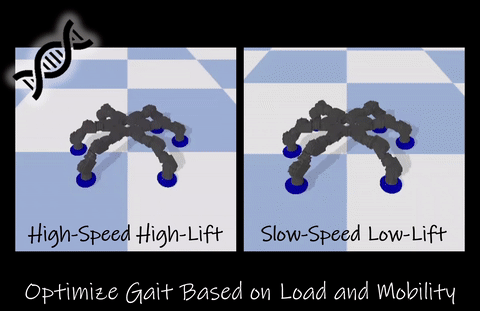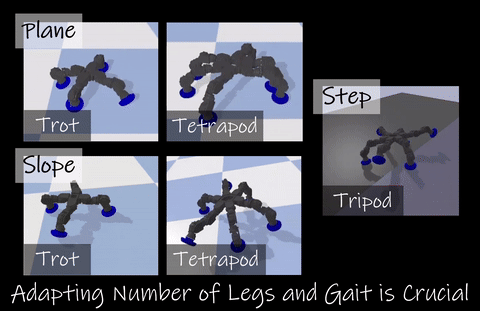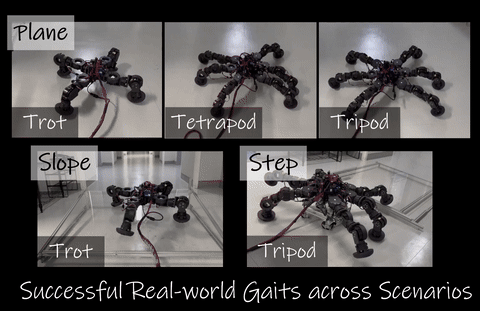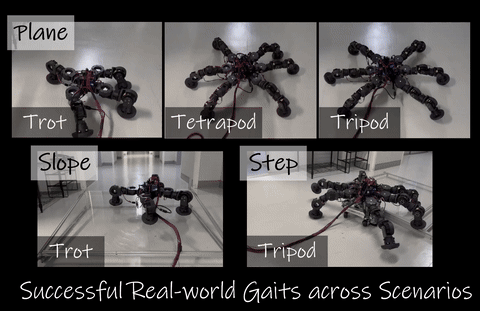
Modular Robot Gait Generation

Modular Robot Gait Generation

Detachable joints introduce load constraints in legged modular robots. Multi-objective gait optimization balances joint load, locomotion speed, and static stability, with four- and six-legged configurations evaluated in simulation and physical experiments.

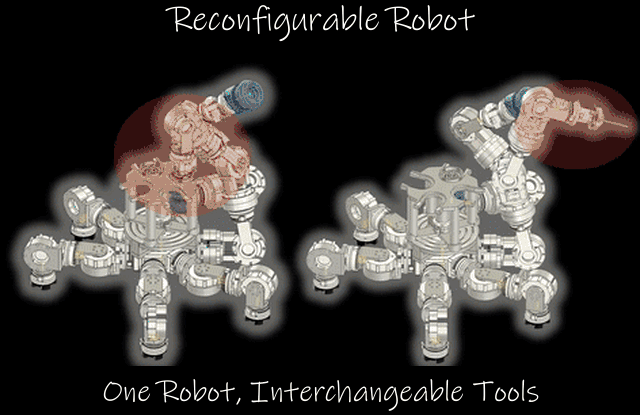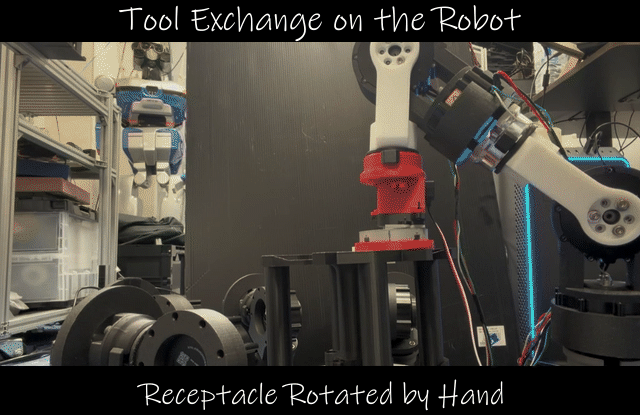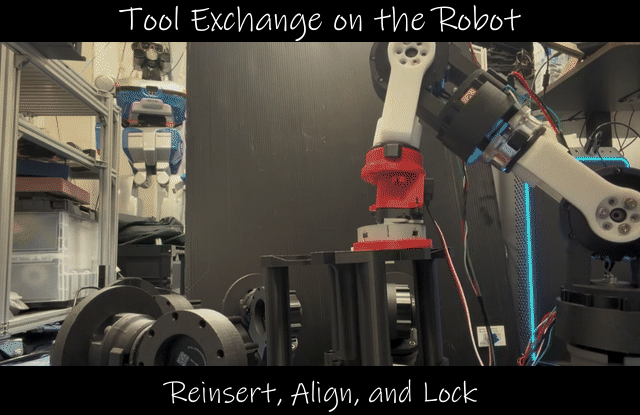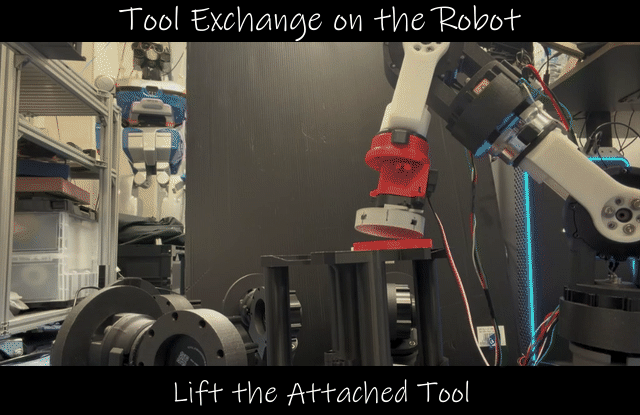
Self-Aligning Tool Changer

Self-Aligning Tool Changer

Triangular lead-in guides and chamfered walls passively correct angular and lateral misalignment during tool exchange. Without force sensors, a rotating station carried by the robot supports tool reconfiguration, with tolerance validated up to ±20° rotation and 7 mm lateral offset.

VLM-Based Replanning

VLM-Based Replanning

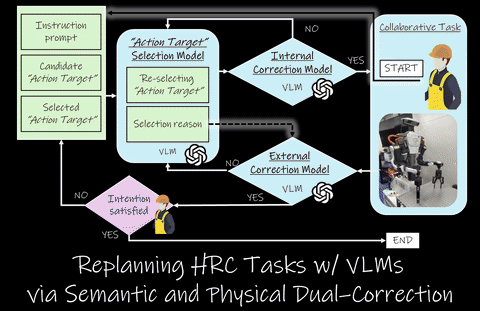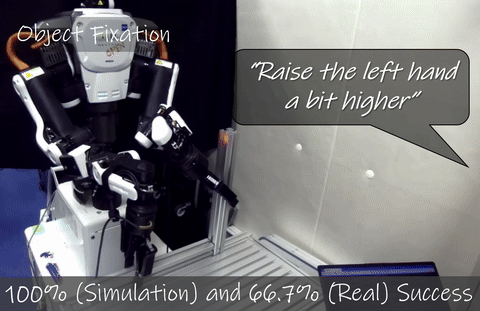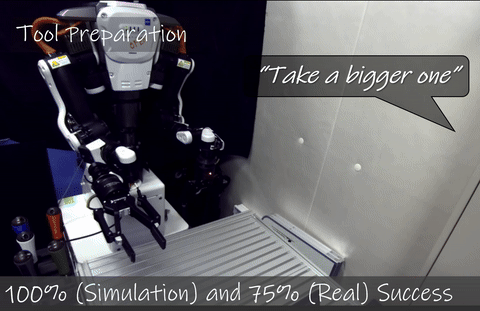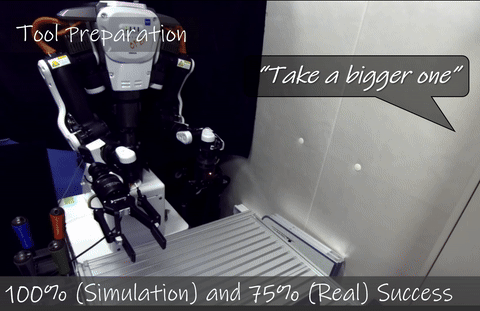
Vision-language models replan human-robot collaborative tasks from ambiguous instructions and visual observations. Internal and external correction mechanisms address semantic and physical execution errors, aligning tasks with human intent in part fastening and tool handovers.

Soft Regrasping Tool

Soft Regrasping Tool

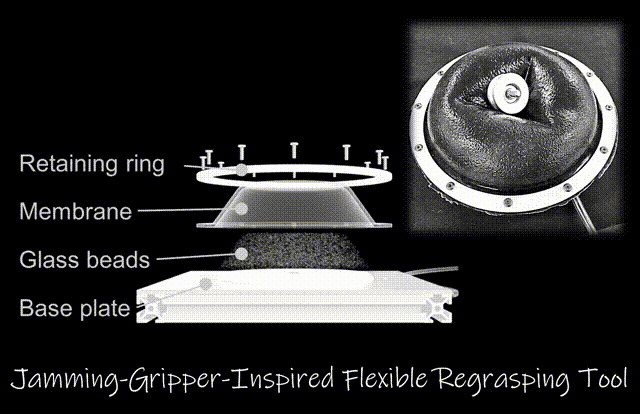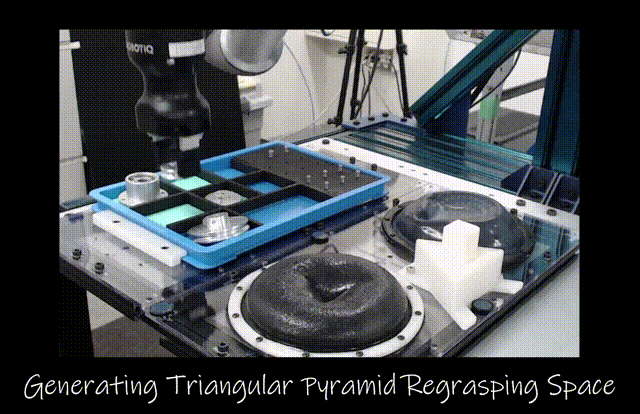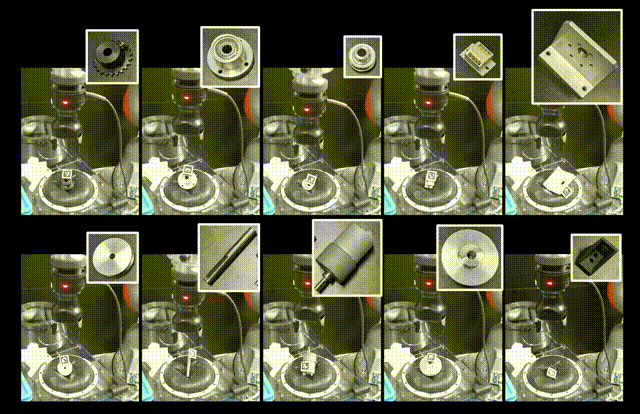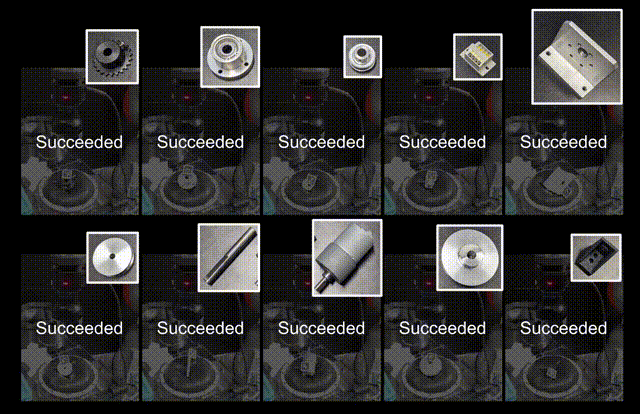
A soft jig inspired by a jamming gripper supports regrasping diverse parts. A cavity within its membrane temporarily holds objects in a stable pose, achieving over 80% success in drop-placement experiments and showing potential as an alternative to rigid fixtures.

Shell-Jig-Based Disassembly

Shell-Jig-Based Disassembly

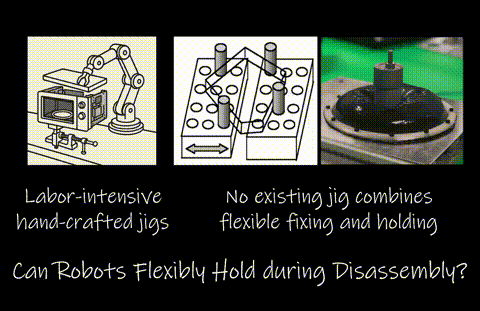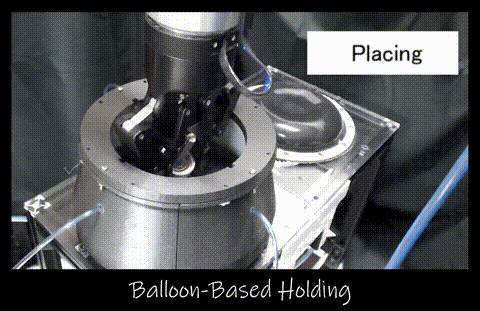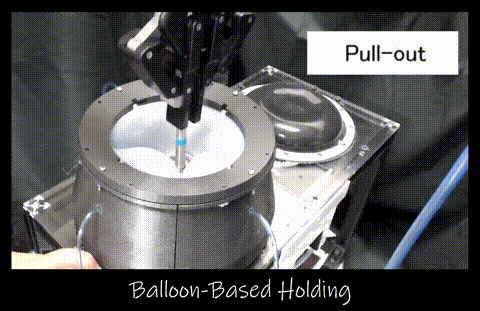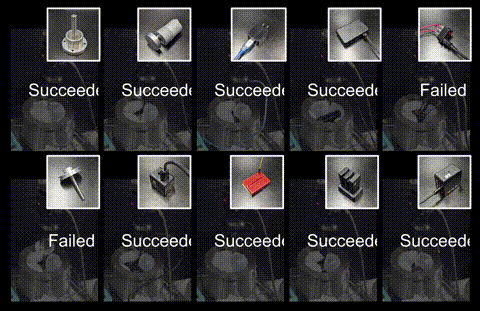
A shell-type soft jig uses surrounding balloons to hold diverse objects without damage, enabling part extraction without dedicated jigs or precise recognition and planning. Experiments on ten objects compared its feasibility with a vise and a jamming soft jig.

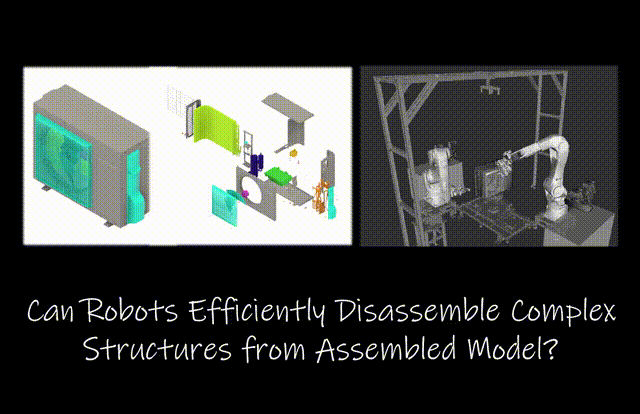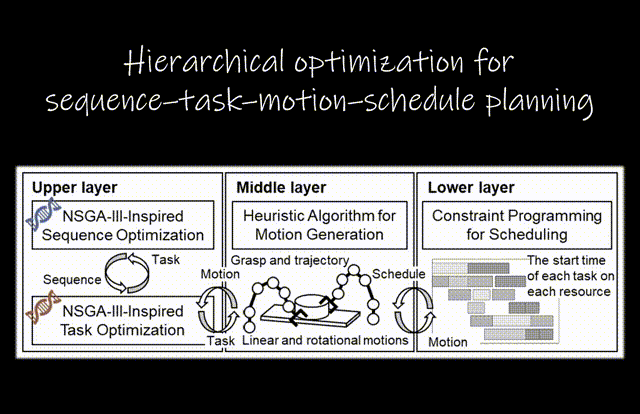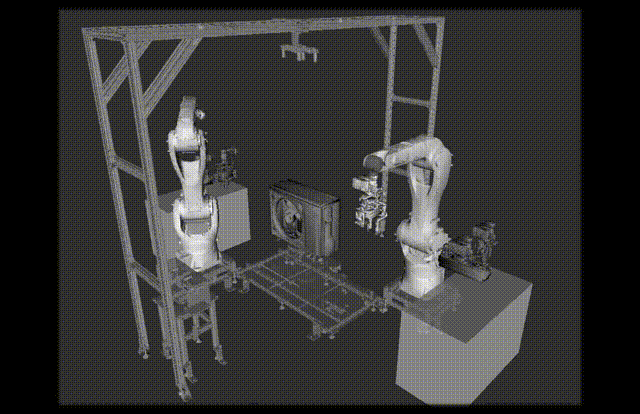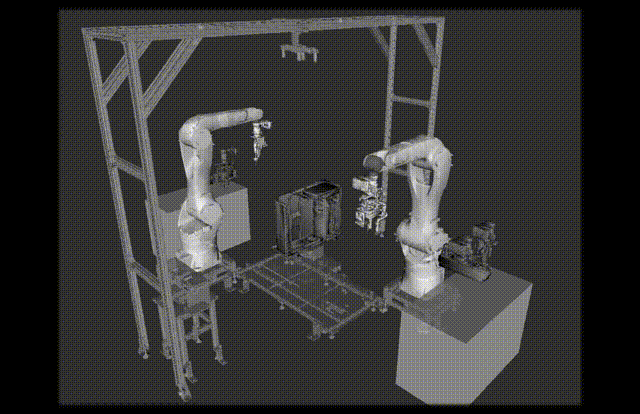
Hierarchical Integrated Task Planning

Hierarchical Integrated Task Planning

Hierarchical optimization plans long-horizon disassembly of constrained structures using a linear-rotary stage and multi-arm robots with diverse tools. Multi-objective genetic algorithms handle sequence-task-motion planning, while constraint programming schedules operations for the reconfigurable system.

Affordance-Guided Operation

Affordance-Guided Operation

Affordance-guided teleoperation visualizes feasible grasps and disassembly directions for dual-arm handling of mating parts, improving operability despite occlusions. Hybrid position-impedance control prevents excessive tracking under load, increasing success rates and reducing object pose deviation in real-robot experiments.

Modular Soft Fixtures and Layout Planning

Modular Soft Fixtures and Layout Planning

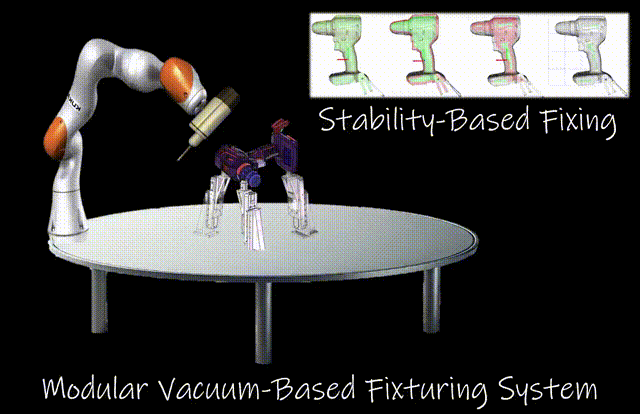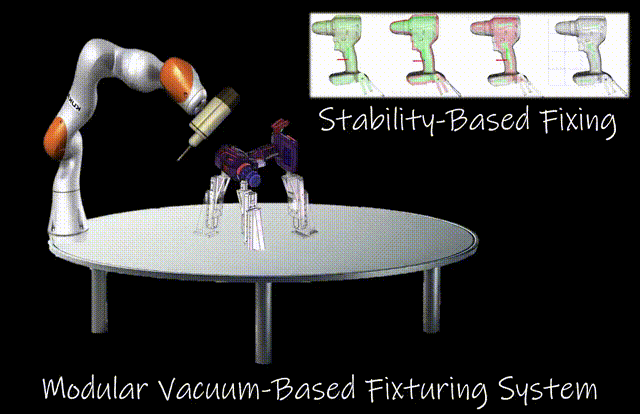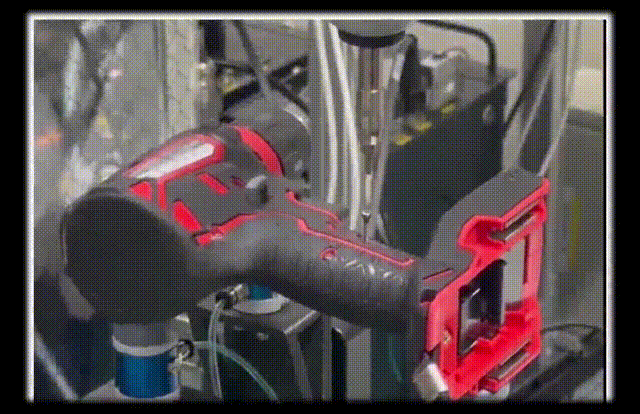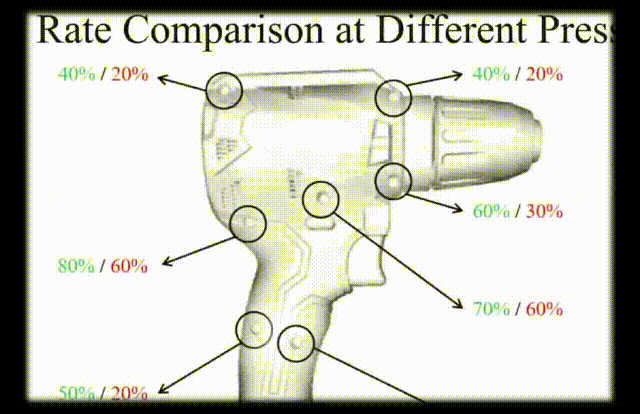
Modular soft vacuum fixtures conform to curved surfaces to support irregular objects. A diffusion model generates layout candidates, refined by Bayesian optimization. Evaluating changing support surfaces, mass distribution, and task loads across all disassembly stages yields one shared layout that avoids fixture reconfiguration.

Graph-Based Task Planning

Graph-Based Task Planning

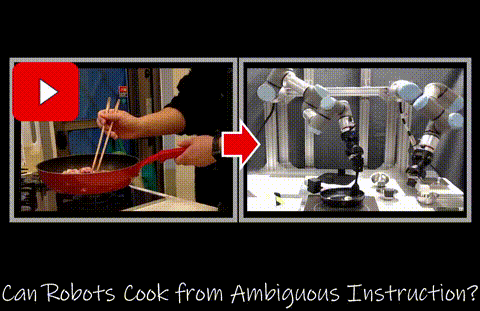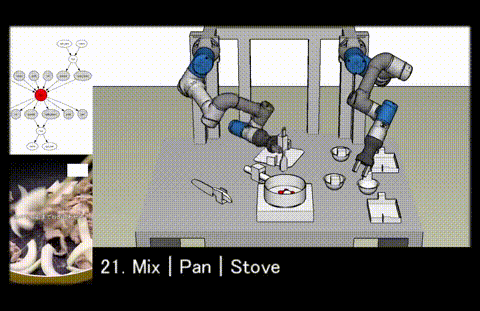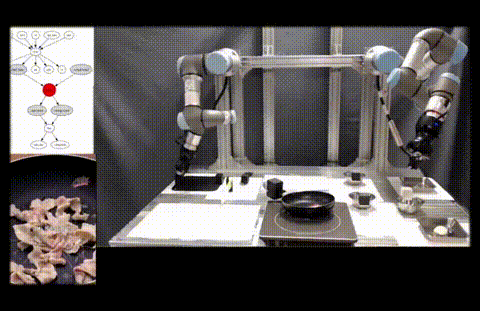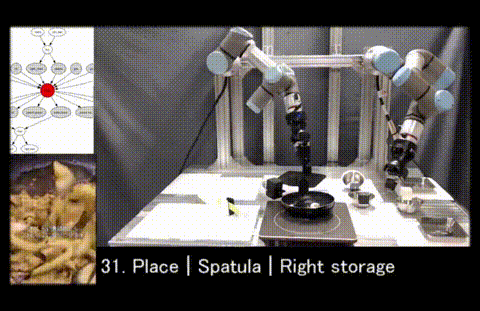
An LLM generates cooking task and motion plans from subtitled videos. Functional Object-Oriented Networks (FOON) validate and refine plans to reduce hallucination and video uncertainty. A dual-arm robot executed four of five recipes, compared with one using an LLM alone.

Dataset Collection for Deep Learning

Dataset Collection for Deep Learning

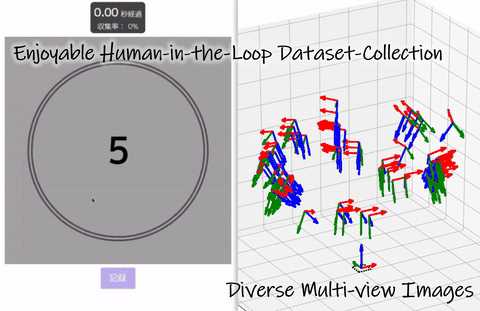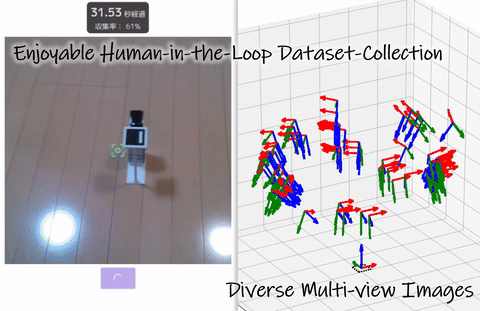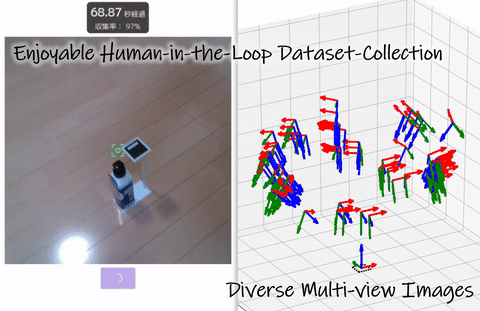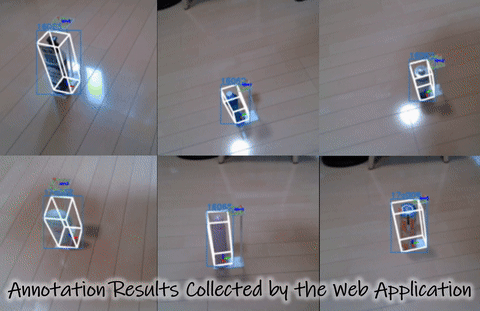
A web-browser interface collects training data for 2D object detection through online visual feedback. Users review and evaluate captured images in real time, with an integrated collection, training, and evaluation pipeline enabling rapid construction of high-quality datasets.

Self-Supervised Mobile Grasping

Self-Supervised Mobile Grasping

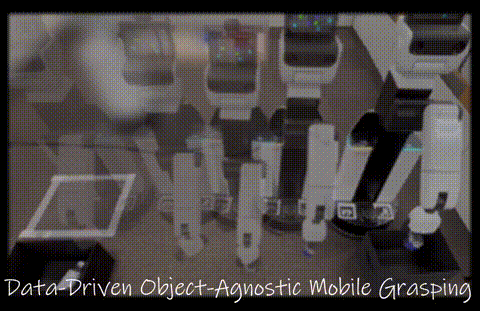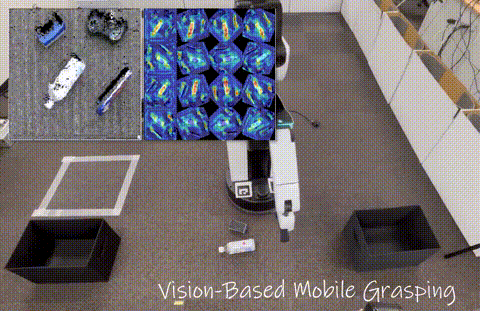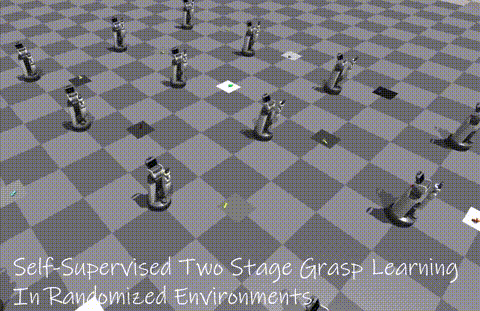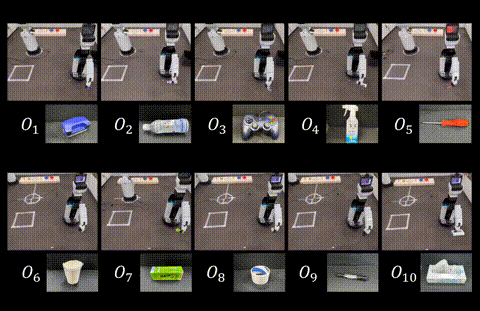
Self-supervised learning adjusts velocity and grasp to object shape for mobile grasping. Three action primitives reduce data sparsity, and three FCNs predict grasps and correct motion errors. Two-stage learning and randomized simulations improve accuracy and generalization across objects and environments.

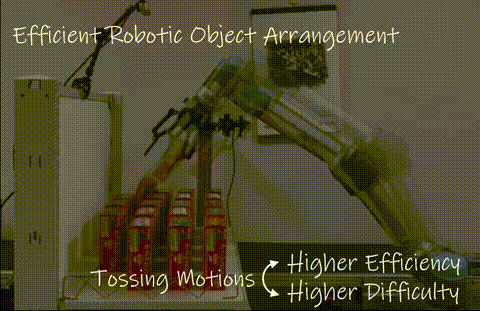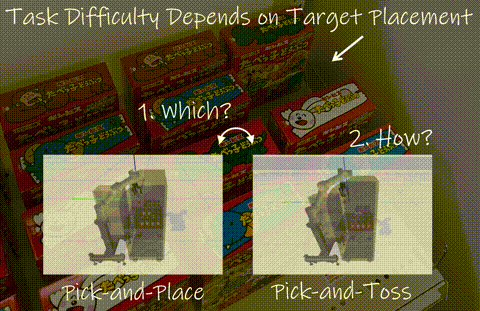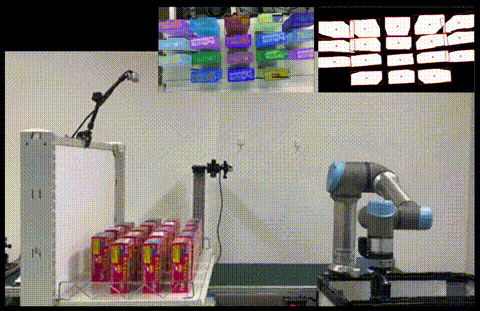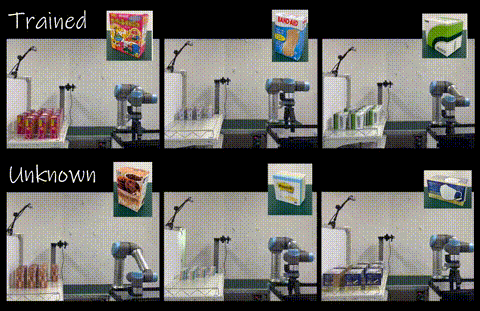
Task-Difficulty-Based Tossing

Task-Difficulty-Based Tossing

Task difficulty derived from placement conditions guides selection between pick-and-place and pick-and-toss, extending the robot’s range while considering toss accuracy. Self-supervised toss learning and brute-force task search were validated through simulations and real-robot experiments arranging rectangular objects.

Multi-Objective Sequence and Motion Planning

Multi-Objective Sequence and Motion Planning

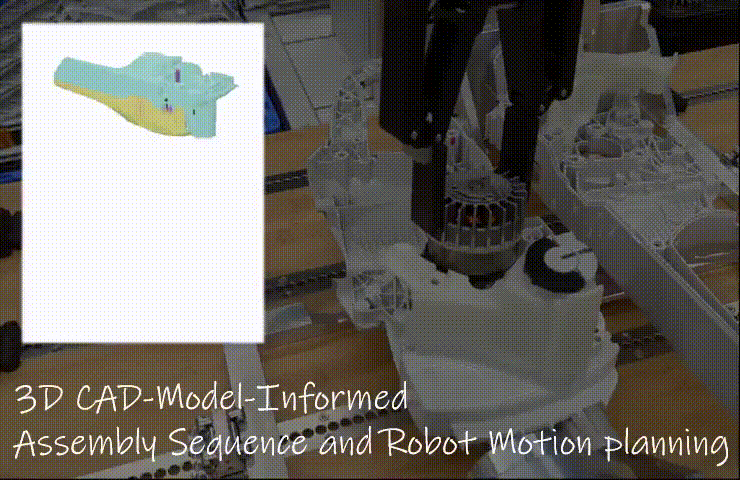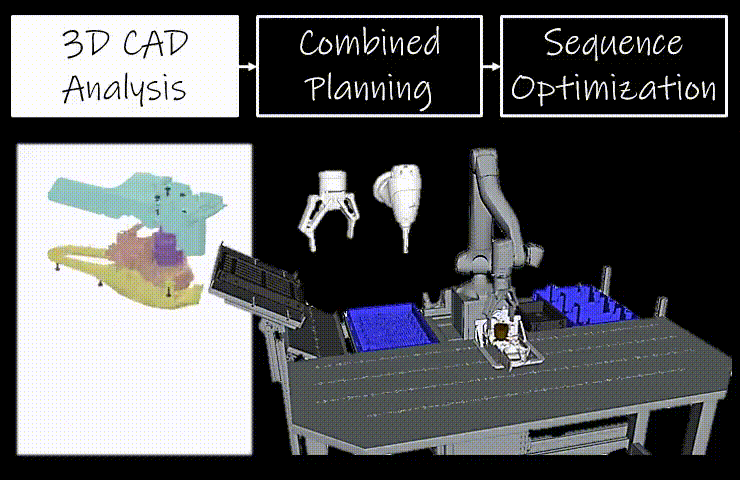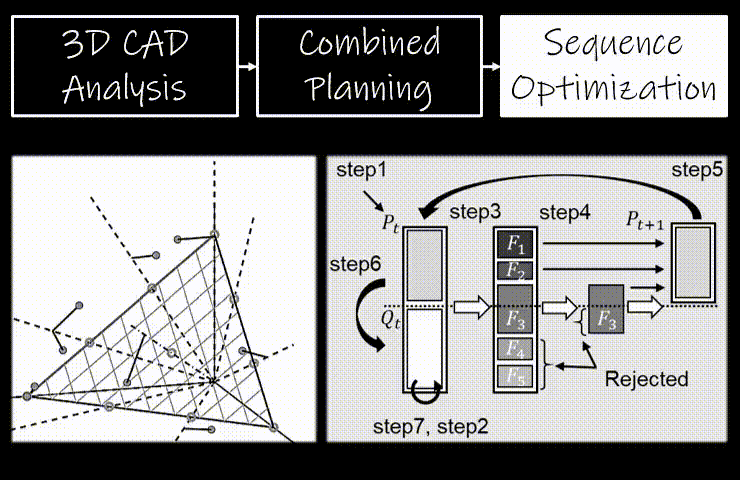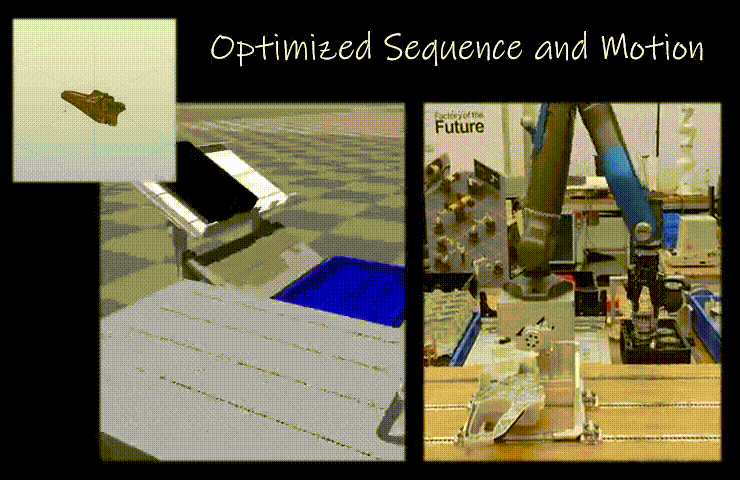
Uncertainty-aware sequence and motion planning addresses assembly of complex mechanical products with many contact points. CAD-based simulation and a many-objective genetic algorithm simultaneously optimize assembly order, object placement, contact-state transitions, grasps, and trajectories for robot execution.

Perceptive Jamming Soft Jig

Perceptive Jamming Soft Jig

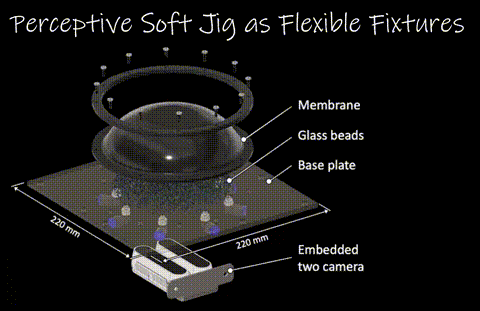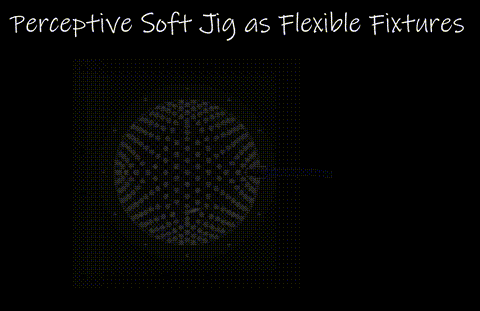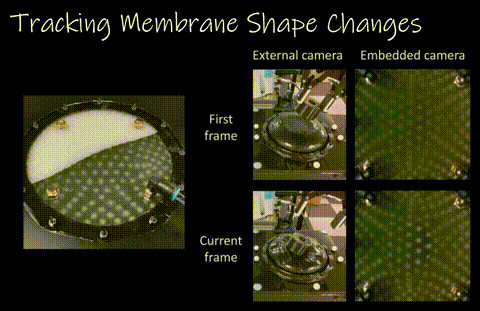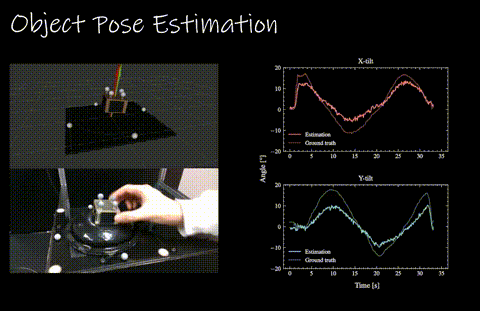
A hydraulically driven soft jig fixes parts through jamming while maintaining optical transparency for visual sensing. Embedded cameras observe the membrane, and movements of markers on its inner surface provide estimates of the fixed object’s pose.

Similarity-Based Novel Object Manipulation

Similarity-Based Novel Object Manipulation

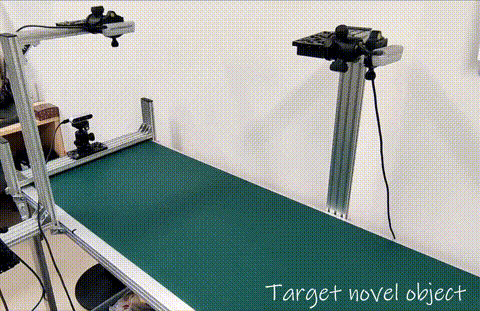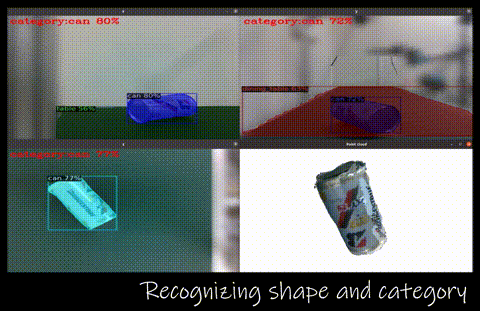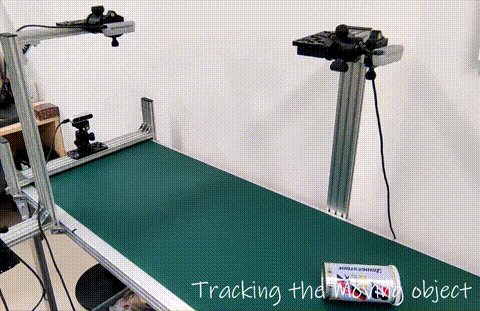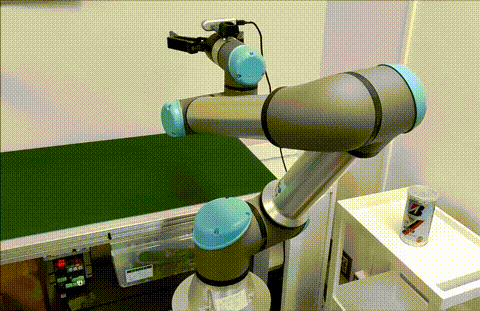
Category association and word embeddings quantify semantic similarity between novel objects and known database objects for accurate, stable pick-and-place. A similarity prediction function selects a model whose preplanned robust grasps are imitated to plan new grasps for real-world target objects.

Quickly Trainable Deep Learning Detector

Quickly Trainable Deep Learning Detector

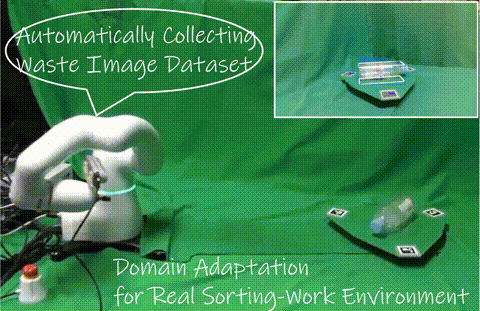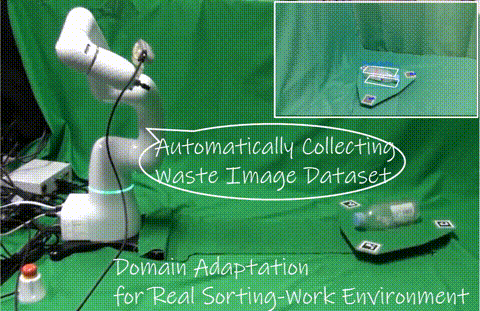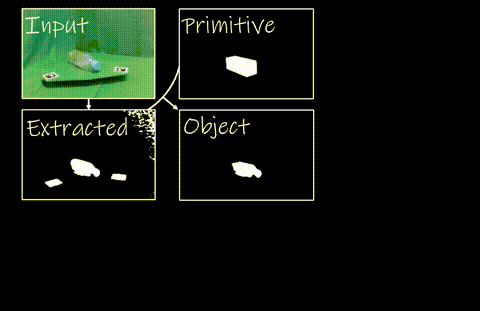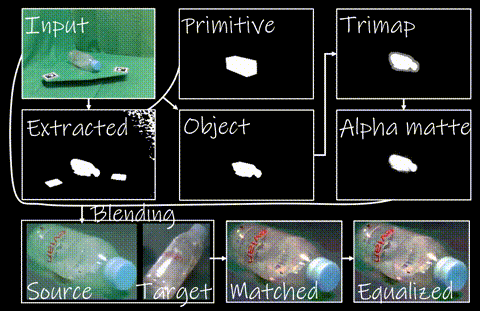
Automated object-image collection quickly builds training data for a deep learning waste detector. Image processing reduces lighting and background differences between collection and sorting scenes, preserving detection performance while combined graspless and grasping actions enable agile waste handling.

CAD-Based Sequence Planning

CAD-Based Sequence Planning

A multiobjective genetic algorithm balances several objectives to generate constraint-satisfied, easy-to-handle assembly sequences for robots. A complementary method extracts part relation matrices from 3D computer-aided design (CAD) models.

Jamming-Gripper-Inspired Jig

Jamming-Gripper-Inspired Jig

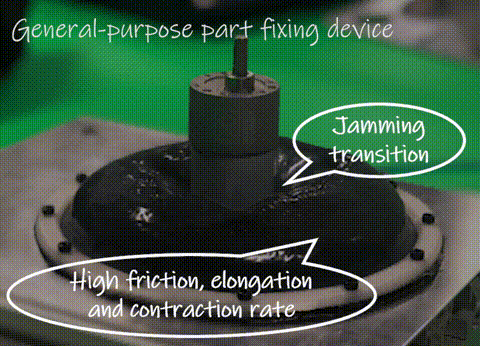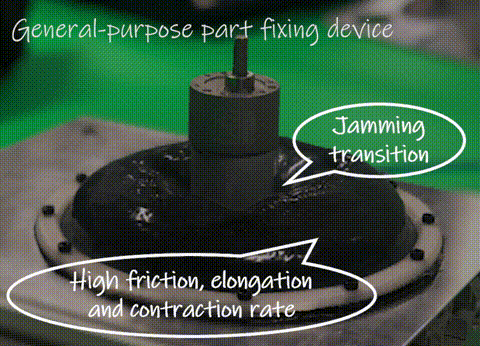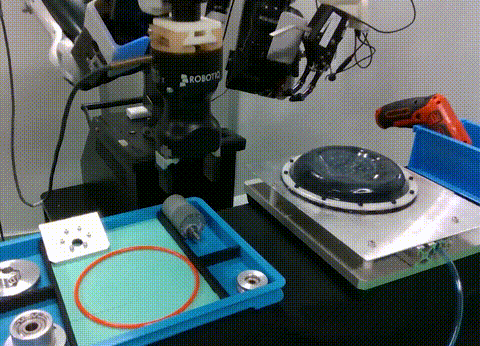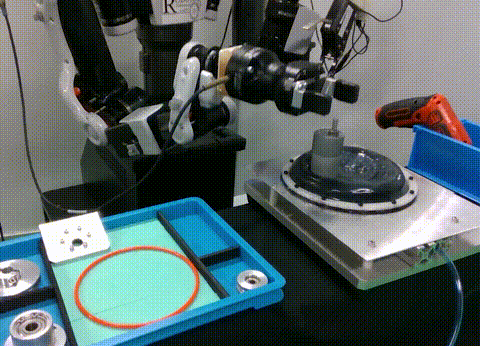
A jamming-gripper-inspired soft jig deforms to fit assembly parts of various shapes. A highly elastic, high-friction silicone membrane filled with glass beads holds parts firmly through jamming transition, supporting flexible assembly systems.

Automatic Annotation with Visual Markers

Automatic Annotation with Visual Markers

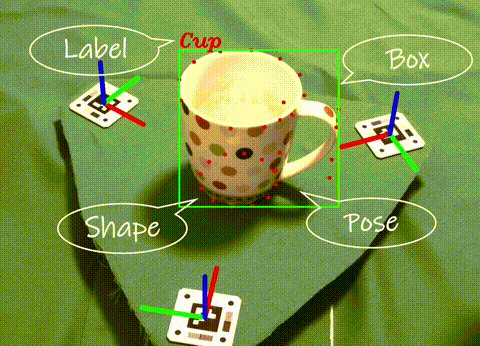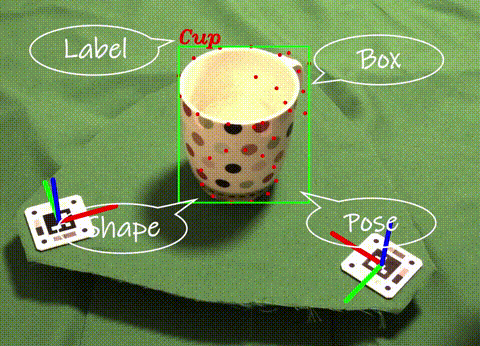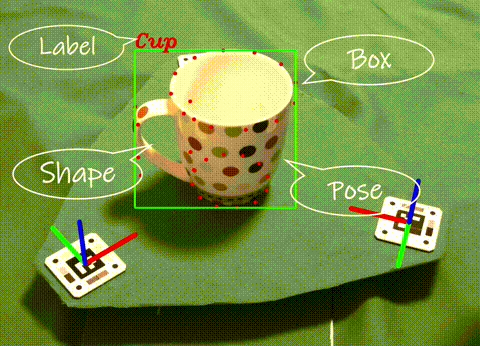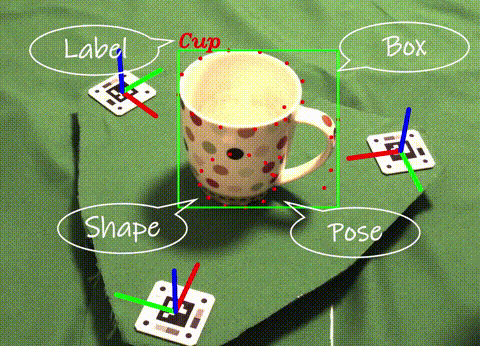
Visual markers captured alongside objects automate image annotation for deep-learning vision systems. A noise mask hides each marker so the network does not learn it as an object feature, reducing erroneous learning and the need for laborious manual annotation.

Tactile-Based Pouring

Tactile-Based Pouring

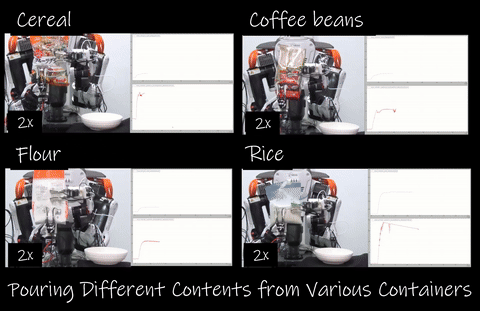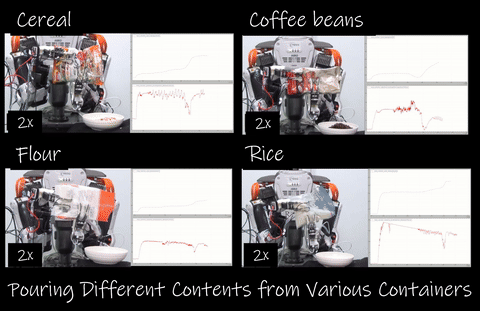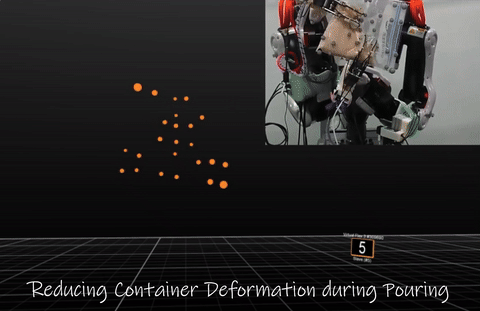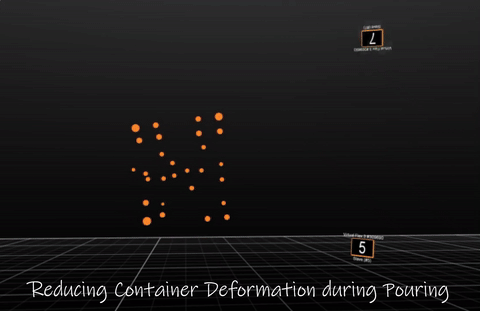
A dual-arm robot uses tactile sensing to pour from deformable containers, supporting the bottom while lifting the top. Experiments with cereal, coffee beans, flour, and rice reduced deformation by 66% compared with single-arm motion and achieved over 90% success.

Biography

Research and education

2021-present

The University of Osaka, Harada Laboratory

2009-2016

NIT, Kumamoto College

  • Advanced Course Student (2014-2016)
    Skeletal Modeling for Forearm Pronation and Supination

  • Technical College Student (2009-2014)
    Artificial-Muscle-Driven Robotic Arm with Biarticular Muscles

Publication

Complete publication list

183 / 183

Journals

30
  1. Takuya Kiyokawa, Tomoki Ishikura, Shingo Hamada, Genichiro Matsuda, and Kensuke Harada:
    ''Component Influence-Driven Fastener Reduction for Robotic Disassemblability-Aware Design Simplification,''
    International Journal of Automation Technology, vol. 20, no. 6, pp. 511-519, 2026. DOI arXiv BibTex
    Cite
    @article{Kiyokawa2026ijat,
    author = {Takuya Kiyokawa and Tomoki Ishikura and Shingo Hamada and Genichiro Matsuda and Kensuke Harada},
    title = {Component Influence-Driven Fastener Reduction for Robotic Disassemblability-Aware Design Simplification},
    journal = {International Journal of Automation Technology},
    volume = {20},
    number = {6},
    pages = {511--519},
    year = {2026}
    }
    
  2. Taichi Kato, Takuya Kiyokawa, Namiko Saito, and Kensuke Harada:
    ''Replanning Human-Robot Collaborative Tasks with Vision-Language Models via Semantic and Physical Dual-Correction,''
    Advanced Robotics, pp. 1-15, 2026 (published online). DOI arXiv YouTube BibTex
    Cite
    @article{Kato2026,
    author = {Taichi Kato and Takuya Kiyokawa and Namiko Saito and Kensuke Harada},
    title = {Replanning Human-Robot Collaborative Tasks with Vision-Language Models via Semantic and Physical Dual-Correction},
    journal = {Advanced Robotics},
    pages = {1--15},
    year = {2026}
    }
    
  3. Tomoki Ishikura, Genichiro Matsuda, Takuya Kiyokawa, and Kensuke Harada:
    ''Industrial-Grade Robust Robot Vision for Screw Detection and Removal under Uneven Conditions,''
    Advanced Robotics, vol. 40, no. 16, pp. 1131-1146, 2026. DOI arXiv YouTube BibTex
    Cite
    @article{Ishikura2026,
    author = {Tomoki Ishikura and Genichiro Matsuda and Takuya Kiyokawa and Kensuke Harada},
    title = {Industrial-Grade Robust Robot Vision for Screw Detection and Removal under Uneven Conditions},
    journal = {Advanced Robotics},
    volume = {40},
    number = {16},
    pages = {1131--1146},
    year = {2026}
    }
    
  4. Zhengtao Hu, Ruishuang Liu, Mocong Qiu, Hao Chen, Liang Du, Takuya Kiyokawa, Weiwei Wan, Jianjun Yuan, and Kensuke Harada:
    ''Planning 6-D Grasps for Two-Finger Grippers Considering Edge and Corner Contacts,''
    IEEE/ASME Transactions on Mechatronics (TMECH), pp. 1-11, 2026. DOI BibTex
    Cite
    @article{Hu2026tmech,
    author = {Zhengtao Hu and Ruishuang Liu and Mocong Qiu and Hao Chen and Liang Du and Takuya Kiyokawa and Weiwei Wan and Jianjun Yuan and Kensuke Harada},
    title = {Planning 6-D Grasps for Two-Finger Grippers Considering Edge and Corner Contacts},
    journal = {IEEE/ASME Transactions on Mechatronics (TMECH)},
    pages = {1--11},
    year = {2026}
    }
    
  5. Vitor Hideyo Isume, Takuya Kiyokawa, Natsuki Yamanobe, Yukiyasu Domae, Weiwei Wan, and Kensuke Harada:
    ''Prompt2Craft: Generating Functional Craft Assemblies With LLMs,''
    IEEE Robotics and Automation Letters (RA-L), vol. 11, no. 7, pp. 7772-7779, July 2026. (presented at IROS2026) DOI arXiv BibTex
    Cite
    @article{Isume2026,
    author = {Vitor Hideyo Isume and Takuya Kiyokawa and Natsuki Yamanobe and Yukiyasu Domae and Weiwei Wan and Kensuke Harada},
    title = {Prompt2Craft: Generating Functional Craft Assemblies With LLMs},
    journal = {IEEE Robotics and Automation Letters (RA-L)},
    volume = {11},
    number = {7},
    pages = {7772--7779},
    month = jul,
    year = {2026}
    }
  6. Radwa Ali, Takuya Kiyokawa, Zhengtao Hu, Weiwei Wan, and Kensuke Harada:
    ''3D Layout Planning for Robotic Workcells with Task-Aware Motion Optimization: Generalization and Real Implementation,''
    Robotics and Computer-Integrated Manufacturing, vol. 101, article 103310, 2026. DOI SSRN BibTex
    Cite
    @article{Ali2026rcim,
    author = {Radwa Ali and Takuya Kiyokawa and Zhengtao Hu and Weiwei Wan and Kensuke Harada},
    title = {3D Layout Planning for Robotic Workcells with Task-Aware Motion Optimization: Generalization and Real Implementation},
    journal = {Robotics and Computer-Integrated Manufacturing},
    volume = {101},
    pages = {103310},
    year = {2026}
    }
  7. Hao Chen, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:
    ''Generalizable task-oriented object grasping through LLM-guided ontology and similarity-based planning,''
    Robotics and Autonomous Systems, vol. 201, article 105442, 2026. DOI SSRN BibTex
    Cite
    @article{Chen2026,
    author = {Hao Chen and Takuya Kiyokawa and Weiwei Wan and Kensuke Harada},
    title = {Generalizable task-oriented object grasping through LLM-guided ontology and similarity-based planning},
    journal = {Robotics and Autonomous Systems},
    volume = {201},
    number = {},
    pages = {105442},
    year = {2026}
    }
    
  8. Hiroki Hanai, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:
    ''Robotic Paper Wrapping by Learning Force Control,''
    IEEE Access, vol. 14, pp. 16596-16604, 2026. DOI arXiv BibTex
    Cite
    @article{Hanai2026,
    author = {Hiroki Hanai and Takuya Kiyokawa and Weiwei Wan and Kensuke Harada},
    title = {Robotic Paper Wrapping by Learning Force Control},
    journal = {IEEE Access},
    volume = {14},
    number = {},
    pages = {16596--16604},
    year = {2026}
    }
  9. Takuya Kiyokawa, Kensuke Harada, Weiwei Wan, Tomoki Ishikura, Naoya Miyaji, and Genichiro Matsuda:
    ''Many-Objective-Optimized Semi-Automated Robotic Disassembly Sequences,''
    Robotics and Autonomous Systems, vol. 197, article 105301, 2026. DOI arXiv YouTube BibTex
    Cite
    @article{Kiyokawa2025dis,
    author = {Takuya Kiyokawa and Kensuke Harada and Weiwei Wan and Tomoki Ishikura and Naoya Miyaji and Genichiro Matsuda},
    title = {Many-Objective-Optimized Semi-Automated Robotic Disassembly Sequences},
    journal = {Robotics and Autonomous Systems},
    volume = {197},
    eid = {105301},
    month = {March},
    year = {2026}
    }
  10. Hao Chen, Takuya Kiyokawa, Zhengtao Hu, Weiwei Wan, and Kensuke Harada:
    ''A Multilevel Similarity Approach for Single-View Object Grasping: Matching, Planning, and Fine-Tuning,''
    IEEE Transactions on Robotics (T-RO), vol. 41, pp. 5966-5985, 2025. (presented at ICRA2026) DOI arXiv BibTex
    Cite
    @article{Chen2025tro,
    author = {Hao Chen and Takuya Kiyokawa and Zhengtao Hu and Weiwei Wan and Kensuke Harada},
    title = {A Multilevel Similarity Approach for Single-View Object Grasping: Matching, Planning, and Fine-Tuning},
    journal = {IEEE Transactions on Robotics (T-RO)},
    volume = {41},
    number = {},
    pages = {5966--5985},
    year = {2025}
    }
    
  11. Takuya Kiyokawa, Naoki Shirakura, Hiroki Katayama, Keita Tomochika, and Jun Takamatsu:
    ''Efficiently Collecting Training Dataset for 2D Object Detection by Online Visual Feedback,''
    Journal of Robotics and Mechatronics, vol. 37, no. 2, pp. 270-283, 2025. DOI arXiv BibTex
    Cite
    @article{Kiyokawa2025web,
    author = {Takuya Kiyokawa and Naoki Shirakura and Hiroki Katayama and Keita Tomochika and Jun Takamatsu},
    title = {Efficiently Collecting Training Dataset for 2D Object Detection by Online Visual Feedback},
    journal = {Journal of Robotics and Mechatronics},
    volume = {37},
    number = {2},
    pages = {270--283},
    year = {2025}
    }
    
  12. Kazuki Higashi, Keisuke Koyama, Fanny Ficuciello, Ryuta Ozawa, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:
    ''Synergy Hand using Fluid Network: Realization of Various Grasping/Manipulation Styles,''
    IEEE Access, vol. 12, pp. 164966-164978, 2024. DOI BibTex
    Cite
    @article{Higashi2024,
    author = {Kazuki Higashi and Keisuke Koyama and Fanny Ficuciello and Ryuta Ozawa and Takuya Kiyokawa and Weiwei Wan and Kensuke Harada},
    title = {Synergy Hand using Fluid Network: Realization of Various Grasping/Manipulation Styles},
    journal = {IEEE Access},
    volume = {12},
    number = {},
    pages = {164966--164978},
    year = {2024}
    }
  13. Zhenting Wang, Takuya Kiyokawa, Natsuki Yamanobe, Weiwei Wan, and Kensuke Harada:
    ''Assembly Task Allocation for Human-Robot Collaboration Considering Stability and Assembly Complexity,''
    IEEE Access, vol. 12, pp. 159821-159832, 2024. DOI BibTex
    Cite
    @article{Wang2024,
    author = {Zhenting Wang and Takuya Kiyokawa and Natsuki Yamanobe and Weiwei Wan and Kensuke Harada},
    title = {Assembly Task Allocation for Human-Robot Collaboration Considering Stability and Assembly Complexity},
    journal = {IEEE Access},
    volume = {12},
    number = {},
    pages = {159821--159832},
    year = {2024}
    }
  14. Vitor Hideyo Isume, Takuya Kiyokawa, Natsuki Yamanobe, Yukiyasu Domae, Weiwei Wan, and Kensuke Harada:
    ''Component Selection for Craft Assembly Tasks,''
    IEEE Robotics and Automation Letters (RA-L), vol. 9, no. 9, pp. 8122-8129, 2024. (presented at ICRA2025) DOI arXiv BibTex
    Cite
    @article{Isume2024,
    author = {Vitor Hideyo Isume and Takuya Kiyokawa and Natsuki Yamanobe and Yukiyasu Domae and Weiwei Wan and Kensuke Harada},
    title = {Component Selection for Craft Assembly Tasks},
    journal = {IEEE Robotics and Automation Letters (RA-L)},
    volume = {9},
    number = {9},
    pages = {8122--8129},
    year = {2024}
    }
    
  15. Takuya Kiyokawa, Jun Takamatsu, and Shigeki Koyanaka:
    ''Challenges for Future Robotic Sorters of Mixed Industrial Waste: A Survey,''
    IEEE Transactions on Automation Science and Engineering (TASE), vol. 21, no 1, pp. 1023-1040, 2024. DOI BibTex
    Cite
    @article{Kiyokawa2024tase,
    author = {Takuya Kiyokawa and Jun Takamatsu and Shigeki Koyanaka},
    title = {Challenges for Future Robotic Sorters of Mixed Industrial Waste: A Survey},
    journal = {IEEE Transactions on Automation Science and Engineering (TASE)},
    volume = {21},
    number = {1},
    pages = {1023--1040},
    year = {2024}
    }
  16. Kazuki Higashi, Keisuke Koyama, Ryuta Ozawa, Kazuyuki Nagata, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:
    ''Torque-sensing Soft Bellows Actuator for Multi-fingered Hands Taking Bellow's Buckling into Consideration,''
    IEEE Access, vol. 11, pp. 129258-129268, 2023. DOI BibTex
    Cite
    @article{Higashi2023,
    author = {Kazuki Higashi and Keisuke Koyama and Ryuta Ozawa and Kazuyuki Nagata and Takuya Kiyokawa and Weiwei Wan and Kensuke Harada},
    title = {Torque-sensing Soft Bellows Actuator for Multi-fingered Hands Taking Bellow's Buckling into Consideration},
    journal = {IEEE Access},
    volume = {11},
    number = {},
    pages = {129258--129268},
    year = {2023}
    }
  17. Zhenting Wang, Takuya Kiyokawa, Issei Sera, Natsuki Yamanobe, Weiwei Wan, and Kensuke Harada:
    ''Error Correction in Robotic Assembly Planning from Graphical Instruction Manuals,''
    IEEE Access, vol. 11, pp. 107276-107286, 2023. DOI BibTex
    Cite
    @article{Wang2023,
    author = {Zhenting Wang and Takuya Kiyokawa and Issei Sera and Natsuki Yamanobe and Weiwei Wan and Kensuke Harada},
    title = {Error Correction in Robotic Assembly Planning from Graphical Instruction Manuals},
    journal = {IEEE Access},
    volume = {11},
    number = {},
    pages = {107276--107286},
    year = {2023}
    }
  18. Sho Kobayashi, Weiwei Wan, Takuya Kiyokawa, Keisuke Koyama, and Kensuke Harada:
    ''Obtaining an Object's 3D Model Using Dual-Arm Robotic Manipulation and Stationary Depth Sensing,''
    IEEE Transactions on Automation Science and Engineering (TASE), vol. 20, no. 3, pp. 2075-2087, 2023. DOI BibTex
    Cite
    @article{Kobayashi2022tase,
    author = {Sho Kobayashi and Weiwei Wan and Takuya Kiyokawa and Keisuke Koyama and Kensuke Harada},
    title = {Obtaining an Object's 3D Model Using Dual-Arm Robotic Manipulation and Stationary Depth Sensing},
    journal = {IEEE Transactions on Automation Science and Engineering (TASE)},
    volume = {20},
    number = {3},
    pages = {2075--2087},
    year = {2023}
    }
  19. Takuya Kiyokawa, Naoki Shirakura, Zhenting Wang, Natsuki Yamanobe, Ixchel G. Ramirez-Alpizar, Weiwei Wan, and Kensuke Harada:
    ''Difficulty and Complexity Definitions for Assembly Task Allocation and Assignment in Human-Robot Collaborations: A Review,''
    Robotics and Computer-Integrated Manufacturing, vol. 84, article 102598, 2023. DOI BibTex
    Cite
    @article{Kiyokawa2023rcim,
    author = {Takuya Kiyokawa and Naoki Shirakura and Zhenting Wang and Natsuki Yamanobe and Ixchel G. Ramirez-Alpizar and Weiwei Wan and Kensuke Harada},
    title = {Difficulty and Complexity Definitions for Assembly Task Allocation and Assignment in Human-robot Collaborations: A Review},
    journal = {Robotics and Computer-Integrated Manufacturing},
    volume = {84},
    year = {2023},
    eid = {102598}
    }
    
  20. Tatsuya Sakuma, Takuya Kiyokawa, Takamitsu Matsubara, Jun Takamatsu, Takahiro Wada, and Tsukasa Ogasawara:
    ''Jamming Gripper-Inspired Soft Jig for Perceptive Parts Fixing,''
    IEEE Access, vol. 11, pp. 62187-62199, 2023. DOI BibTex
    Cite
    @article{Sakuma2023,
    author = {Tatsuya Sakuma and Takuya Kiyokawa and Takamitsu Matsubara and Jun Takamatsu and Takahiro Wada and Tsukasa Ogasawara},
    title = {Jamming Gripper-Inspired Soft Jig for Perceptive Parts Fixing},
    journal = {IEEE Access},
    volume = {11},
    number = {},
    pages = {62187--62199},
    year = {2023}
    }
  21. Yuan Gao, Shogo Matsuoka, Weiwei Wan, Takuya Kiyokawa, Keisuke Koyama, and Kensuke Harada:
    ''In-Hand Pose Estimation Using Hand-Mounted RGB Cameras and Visuotactile Sensors,''
    IEEE Access, vol. 11, pp. 17218-17232, 2023. DOI BibTex
    Cite
    @article{Gao2023access,
    author = {Yuan Gao and Shogo Matsuoka and Weiwei Wan and Takuya Kiyokawa and Keisuke Koyama and Kensuke Harada},
    title = {In-Hand Pose Estimation Using Hand-Mounted {RGB} Cameras and Visuotactile Sensors},
    journal = {IEEE Access},
    volume = {11},
    number = {},
    pages = {17218--17232},
    year = {2023}
    }
  22. Kota Takata, Takuya Kiyokawa, Natsuki Yamanobe, Ixchel G. Ramirez-Alpizar, Weiwei Wan, and Kensuke Harada:
    ''Graph-Based Framework on Bimanual Manipulation Planning from Cooking Recipe,''
    MDPI Robotics, vol. 11, no. 6, article 123, 2022. DOI Preprints BibTex
    Cite
    @article{Takata2022robotics,
    author = {Kota Takata and Takuya Kiyokawa and Natsuki Yamanobe and Ixchel G. Ramirez-Alpizar and Weiwei Wan and Kensuke Harada},
    title = {Graph-Based Framework on Bimanual Manipulation Planning from Cooking Recipe},
    journal = {Robotics},
    volume = {11},
    number = {6},
    eid = {123},
    year = {2022}
    }
  23. Enrique Coronado, Takuya Kiyokawa, Gustavo A. Garcia Ricardez, Ixchel G. Ramirez-Alpizar, Gentiane Venture, and Natsuki Yamanobe:
    ''Evaluating Quality in Human-Robot Interaction: a Systematic Search and Classification of Performance and Human-Centered Factors, Measures and Metrics towards an Industry 5.0,''
    Journal of Manufacturing Systems, vol. 63, pp. 392-410, 2022. DOI BibTex
    Cite
    @article{Coronado2022,
    author = {Enrique Coronado and Takuya Kiyokawa and Gustavo A. Garcia Ricardez and Ixchel G. Ramirez-Alpizar and Gentiane Venture and Natsuki Yamanobe},
    title = {Evaluating Quality in Human-Robot Interaction: A Systematic Search and Classification of Performance and Human-centered Factors, Measures and Metrics towards An {Industry 5.0}},
    journal = {Journal of Manufacturing Systems},
    volume = {63},
    number = {},
    pages = {392--410},
    year = {2022}
    }
  24. Hao Chen, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:
    ''Category-Association Based Similarity Matching for Novel Object Pick-and-Place Task,''
    IEEE Robotics and Automation Letters (RA-L), vol. 7, no. 2, pp. 2961-2968, 2022. (presented at ICRA2022) DOI arXiv BibTex
    Cite
    @article{Chen2022,
    author = {Hao Chen and Takuya Kiyokawa and Weiwei Wan and Kensuke Harada},
    title = {Category-Association Based Similarity Matching for Novel Object Pick-and-Place Task},
    journal = {IEEE Robotics and Automation Letters (RA-L)},
    volume = {7},
    number = {2},
    pages = {2961--2968},
    year = {2022}
    }
  25. Takuya Kiyokawa, Hiroki Katayama, Yuya Tatsuta, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Robotic Waste Sorter with Agile Manipulation and Quickly Trainable Detector,''
    IEEE Access, vol. 9, pp. 124616-124631, 2021. DOI arXiv BibTex
    Cite
    @article{Kiyokawa2021sorter,
    author = {Takuya Kiyokawa and Hiroki Katayama and Yuya Tatsuta and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Robotic Waste Sorter with Agile Manipulation and Quickly Trainable Detector},
    journal = {IEEE Access},
    volume = {9},
    number = {},
    pages = {124616--124631},
    year = {2021}
    }
  26. Naoki Shirakura, Takuya Kiyokawa, Hikaru Kumamoto, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Collection of Marine Debris by Jointly Using UAV-UUV with GUI for Simple Operation,''
    IEEE Access, vol. 9, pp. 67432-67443, 2021. DOI BibTex
    Cite
    @article{Shirakura2021,
    author = {Naoki Shirakura and Takuya Kiyokawa and Hikaru Kumamoto and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Collection of Marine Debris by Jointly Using {UAV-UUV} with {GUI} for Simple Operation},
    journal = {IEEE Access},
    volume = {9},
    number = {},
    pages = {67432--67443},
    year = {2021}
    }
  27. Kento Tariki, Takuya Kiyokawa, Tomoki Nagatani, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Generating Complex Assembly Sequences from 3D CAD Models Considering Insertion Relations,''
    Advanced Robotics, vol. 35, no. 6, pp. 337-348, 2021. DOI BibTex
    Cite
    @article{Tariki2021ar,
    author = {Kento Tariki and Takuya Kiyokawa and Tomoki Nagatani and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Generating complex assembly sequences from 3D {CAD} models considering insertion relations},
    journal = {Advanced Robotics},
    volume = {35},
    number = {6},
    pages = {337--348},
    year = {2021}
    }
  28. Takuya Kiyokawa, Keita Tomochika, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Efficient Collection and Automatic Annotation of Real-World Object Images by Taking Advantage of Post-Diminished Multiple Visual Markers,''
    Advanced Robotics, vol. 33, no. 24, pp. 1264-1280, 2019. DOI BibTex
    Cite
    @article{Kiyokawa2019ar,
    author = {Takuya Kiyokawa and Keita Tomochika and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Efficient Collection and Automatic Annotation of Real-world Object Images by Taking Advantage of Post-diminished Multiple Visual Markers},
    journal = {Advanced Robotics},
    volume = {33},
    number = {24},
    pages = {1264--1280},
    year = {2019}
    }
  29. Yuto Tsuchiya, Takuya Kiyokawa, Gustavo Alfonso Garcia Ricardez, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Pouring from Deformable Containers Based on Tactile Information Using a Dual-Arm Robot,''
    International Journal of Robotic Computing (IJRC), vol. 1, no. 2, pp. 123-143, 2019. (presented at IRC2019) DOI PDF BibTex
    Cite
    @article{Tsuchiya2019ijrc,
    author = {Yuto Tsuchiya and Takuya Kiyokawa and Gustavo Alfonso Garcia Ricardez and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Pouring from Deformable Containers Based on Tactile Information Using a Dual-Arm Robot},
    journal = {International Journal of Robotic Computing (IJRC)},
    volume = {1},
    number = {2},
    pages = {123--143},
    year = {2019}
    }
    
  30. Takuya Kiyokawa, Keita Tomochika, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Fully Automated Annotation with Noise-Masked Visual Markers for Deep-Learning-Based Object Detection,''
    IEEE Robotics and Automation Letters (RA-L), vol. 4, no. 2, pp. 1972-1977, 2019. (presented at ICRA2019) DOI BibTex
    Cite
    @article{Kiyokawa2019ral,
    author = {Takuya Kiyokawa and Keita Tomochika and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Fully Automated Annotation With Noise-Masked Visual Markers for Deep-Learning-Based Object Detection},
    journal = {IEEE Robotics and Automation Letters (RA-L)},
    volume = {4},
    number = {2},
    pages = {1972--1977},
    year = {2019}
    }
International Conferences

35
  1. Kennosuke Chihara, Takuya Kiyokawa, Tetsuya Shitara, and Kensuke Harada:
    ''Gait Generation Balancing Joint Load and Mobility for Legged Modular Robots with Easily Detachable Joints,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), Kobe, Japan, January 2027. arXiv BibTex
    Cite
    @inproceedings{Chihara2026,
    author = {Kennosuke Chihara and Takuya Kiyokawa and Tetsuya Shitara and Kensuke Harada},
    title = {Gait Generation Balancing Joint Load and Mobility for Legged Modular Robots with Easily Detachable Joints},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    address = {Kobe, Japan},
    year = {2027}
    }
    
  2. Kazuki Higashi, Takuya Kiyokawa, and Mitsuru Higashimori:
    ''Task-Driven Self-Reconfiguration of Finger-Joint Functions for Dexterous Hand Manipulation,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), Kobe, Japan, January 2027. BibTex
    Cite
    @inproceedings{Higashi2027,
    author = {Kazuki Higashi and Takuya Kiyokawa and Mitsuru Higashimori},
    title = {Task-Driven Self-Reconfiguration of Finger-Joint Functions for Dexterous Hand Manipulation},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    address = {Kobe, Japan},
    year = {2027}
    }
    
  3. Mahfudz Maskur, Takuya Kiyokawa, and Kensuke Harada:
    ''Designing and Validating a Self-Aligning Tool Changer for Modular Reconfigurable Manipulation Robots,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), Kobe, Japan, January 2027. arXiv BibTex
    Cite
    @inproceedings{Maskur2026,
    author = {Mahfudz Maskur and Takuya Kiyokawa and Kensuke Harada},
    title = {Designing and Validating a Self-Aligning Tool Changer for Modular Reconfigurable Manipulation Robots},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    address = {Kobe, Japan},
    year = {2027}
    }
    
  4. Masaki Tsutsumi, Takuya Kiyokawa, Gen Sako, and Kensuke Harada:
    ''Affordance-Guided Enveloping Grasp Demonstration Toward Non-destructive Disassembly of Pinch-Infeasible Mating Parts,''
    in Proceedings of IEEE International Conference on Robot and Human Interactive Communication (RO-MAN), pp. 185-190, Kitakyushu, Japan, August 2026. DOI arXiv YouTube BibTex
    Cite
    @inproceedings{Tsutsumi2026,
    author = {Masaki Tsutsumi and Takuya Kiyokawa and Gen Sako and Kensuke Harada},
    title = {Affordance-Guided Enveloping Grasp Demonstration Toward Non-destructive Disassembly of Pinch-Infeasible Mating Parts},
    booktitle = {Proceedings of IEEE International Conference on Robot and Human Interactive Communication (RO-MAN)},
    pages = {185--190},
    year = {2026}
    }
  5. Takuya Kiyokawa, Zhengtao Hu, Weiwei Wan, and Kensuke Harada:
    ''Soft Regrasping Tool Inspired by Jamming Gripper,''
    in Proceedings of IEEE International Conference on Mechatronics and Automation (ICMA), pp. 1588-1593, Changchun, Jilin, China, August 2026. DOI arXiv YouTube BibTex
    Cite
    @inproceedings{Kiyokawa2026regrasp,
    author = {Takuya Kiyokawa and Zhengtao Hu and Weiwei Wan and Kensuke Harada},
    title = {Soft Regrasping Tool Inspired by Jamming Gripper},
    booktitle = {Proceedings of IEEE International Conference on Mechatronics and Automation (ICMA)},
    pages={1588--1593},
    year = {2026}
    }
    
  6. Takuya Kiyokawa, Ryunosuke Takebayashi, and Kensuke Harada:
    ''Shell-Type Soft Jig for Holding Objects during Disassembly,''
    in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), pp. 701-706, Vienna, Austria, June 2026. DOI arXiv YouTube BibTex
    Cite
    @inproceedings{Kiyokawa2026icra,
    author = {Takuya Kiyokawa and Ryunosuke Takebayashi and Kensuke Harada},
    title = {Shell-Type Soft Jig for Holding Objects during Disassembly},
    booktitle = {Proceedings of IEEE International Conference on Robotics and Automation (ICRA)},
    pages = {701--706},
    year = {2026}
    }
    
  7. Kento Yamada, Prashant Kumar, Yukiyasu Domae, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:
    ''Depth Estimation for Picking Transparent Objects Using a Polarization Camera,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 908-915, Cancun, Mexico, January 2026. DOI BibTex
    Cite
    @inproceedings{Yamada2026,
    author = {Kento Yamada and Prashant Kumar and Yukiyasu Domae and Takuya Kiyokawa and Weiwei Wan and Kensuke Harada},
    title = {Depth Estimation for Picking Transparent Objects Using a Polarization Camera},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {908--915},
    year = {2026}
    }
  8. Takuya Kiyokawa, Tomoki Ishikura, Shingo Hamada, Genichiro Matsuda, and Kensuke Harada:
    ''Hierarchical Planning and Scheduling for Reconfigurable Multi-Robot Disassembly Systems under Structural Constraints,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 233-238, Cancun, Mexico, January 2026. arXiv DOI YouTube BibTex
    Cite
    @inproceedings{Kiyokawa2026schedule,
    author = {Takuya Kiyokawa and Tomoki Ishikura and Shingo Hamada and Genichiro Matsuda and Kensuke Harada},
    title = {Hierarchical Planning and Scheduling for Reconfigurable Multi-Robot Disassembly Systems under Structural Constraints},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {233--238},
    year = {2026}
    }
  9. Haohui Pan, Takuya Kiyokawa, Tomoki Ishikura, Shingo Hamada, Genichiro Matsuda, and Kensuke Harada:
    ''Modular Vacuum-Based Fixturing System for Adaptive Disassembly Workspace Integration,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 219-226, Cancun, Mexico, January 2026. arXiv DOI BibTex
    Cite
    @inproceedings{Pan2026,
    author = {Haohui Pan and Takuya Kiyokawa and Tomoki Ishikura and Shingo Hamada and Genichiro Matsuda and Kensuke Harada},
    title = {Modular Vacuum-Based Fixturing System for Adaptive Disassembly Workspace Integration},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {219--226},
    year = {2026}
    }
  10. Gen Sako, Takuya Kiyokawa, Kensuke Harada, Tomoki Ishikura, Naoya Miyaji, and Genichiro Matsuda:
    ''Affordance-Guided Dual-Armed Disassembly Teleoperation for Mating Parts,''
    in EcoDesign Accelerating Social Transformation: Volume I, pp. 293-309, Springer, Singapore, 2026.
    (presented at EcoDesign2025, P-23, Tokyo, Japan, November 2025). DOI BibTex
    Cite
    @incollection{Sako2025,
    author = {Gen Sako and Takuya Kiyokawa and Kensuke Harada and Tomoki Ishikura and Naoya Miyaji and Genichiro Matsuda},
    title = {Affordance-Guided Dual-Armed Disassembly Teleoperation for Mating Parts},
    booktitle = {{EcoDesign} Accelerating Social Transformation: Volume {I}},
    pages = {293--309},
    year = {2026}
    }
  11. Radwa Ali, Zhengtao Hu, Takuya Kiyokawa, Weiwei Wan, Tatsushi Nishi, and Kensuke Harada:
    ''Task and Grasp Constrained 3D Robotic Work-Cell Layout Planning,''
    in Proceedings of IEEE International Conference on Automation Science and Engineering (CASE), pp. 2355-2362, Los Angeles, US, August 2025
    (IEEE RAS Japan Joint Chapter Young Award). DOI BibTex
    Cite
    @inproceedings{Radwa2025,
    author = {Radwa Ali and Zhengtao Hu and Takuya Kiyokawa and Weiwei Wan and Tatsushi Nishi and Kensuke Harada},
    title = {Task and Grasp Constrained 3D Robotic Work-Cell Layout Planning},
    booktitle = {Proceedings of IEEE International Conference on Automation Science and Engineering (CASE)},
    pages = {2355--2362},
    year = {2025}
    }
  12. Ryunosuke Takebayashi, Vitor Hideyo Isume, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:
    ''Cooking Task Planning using LLM and Verified by Graph Network,''
    in Proceedings of IEEE International Conference on Automation Science and Engineering (CASE), pp. 735-742, Los Angeles, US, August 2025. DOI BibTex
    Cite
    @inproceedings{Takebayashi2025,
    author = {Ryunosuke Takebayashi and Vitor Hideyo Isume and Takuya Kiyokawa and Weiwei Wan and Kensuke Harada},
    title = {Cooking Task Planning using LLM and Verified by Graph Network},
    booktitle = {Proceedings of IEEE International Conference on Automation Science and Engineering (CASE)},
    pages = {735--742},
    year = {2025}
    }
  13. Hao Chen, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:
    ''Adaptive Grasping of Moving Objects in Dense Clutter via Global-to-Local Detection and Static-to-Dynamic Planning,''
    in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), pp. 14059-14065, Atlanta, US, May 2025. arXiv DOI BibTex
    Cite
    @inproceedings{Chen2025icra,
    author = {Hao Chen and Takuya Kiyokawa and Weiwei Wan and Kensuke Harada},
    title = {Adaptive Grasping of Moving Objects in Dense Clutter via Global-to-Local Detection and Static-to-Dynamic Planning},
    booktitle = {Proceedings of IEEE International Conference on Robotics and Automation (ICRA)},
    pages = {14059--14065},
    year = {2025}
    }
    
  14. Hiroshi Tanaka, Masato Tsuru, Takuya Kiyokawa, and Kensuke Harada:
    ''Painting Task Planning for Large Structure using a Mobile Manipulator,''
    in Proceedings of International Conference on Artificial Life and Robotics (ICAROB), vol. 30, pp. 440-444, Oita, Japan, February 2025. BibTex DOI
    Cite
    @inproceedings{Tanaka2025,
    author = {Hiroshi Tanaka and Masato Tsuru and Takuya Kiyokawa and Kensuke Harada},
    title = {Painting Task Planning for Large Structure using a Mobile Manipulator},
    booktitle = {Proceeding of International Conference on Artificial Life and Robotics (ICAROB)},
    volume = {30},
    pages = {440--444},
    year = {2025}
    }
  15. Chenxi Wang, Zhenting Wang, Takuya Kiyokawa, Weiwei Wan, Natsuki Yamanobe, and Kensuke Harada:
    ''Vision-based Robotic Assembly from Novel Graphical Instructions,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 1221-1228, Munich, Germany, January 2025. DOI BibTex
    Cite
    @inproceedings{Wang2025,
    author = {Chenxi Wang and Zhenting Wang and Takuya Kiyokawa and Weiwei Wan and Natsuki Yamanobe and Kensuke Harada},
    title = {Vision-based Robotic Assembly from Novel Graphical Instructions},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {1221--1228},
    year = {2025}
    }
  16. Takuya Kiyokawa, Eiki Nagata, Yoshihisa Tsurumine, Yuhwan Kwon, and Takamitsu Matsubara:
    ''Self-Supervised Learning of Grasping Arbitrary Objects On-the-Move,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 965-972, Munich, Germany, January 2025
    (SICE International Young Authors Award (SIYA)). arXiv DOI YouTube BibTex
    Cite
    @inproceedings{Kiyokawa2025movegrasp,
    author = {Takuya Kiyokawa and Eiki Nagata and Yoshihisa Tsurumine and Yuhwan Kwon and Takamitsu Matsubara},
    title = {Self-Supervised Learning of Grasping Arbitrary Objects On-the-Move},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {965--972},
    year = {2025}
    }
  17. Takuya Kiyokawa, Hiroki Katayama, Jun Takamatsu, and Kensuke Harada:
    ''Active Vapor-Based Robotic Wiper,''
    in Proceedings of IEEE International Conference on Robotic Computing (IRC), pp. 245-248, Tokyo, Japan, December 2024. arXiv DOI BibTex
    Cite
    @inproceedings{Kiyokawa2024wiper,
    author = {Takuya Kiyokawa and Hiroki Katayama and Jun Takamatsu and Kensuke Harada},
    title = {Active Vapor-Based Robotic Wiper},
    booktitle = {Proceedings of IEEE International Conference on Robotic Computing (IRC)},
    pages = {245--248},
    year = {2024}
    }
  18. Takuya Kiyokawa, Mahiro Muta, Weiwei Wan, and Kensuke Harada:
    ''Task-Difficulty-Aware Efficient Object Arrangement Leveraging Tossing Motions,''
    in Proceedings of IEEE International Conference on Robotic Computing (IRC), pp. 170-173, Tokyo, Japan, December 2024. arXiv DOI BibTex
    Cite
    @inproceedings{Kiyokawa2024toss,
    author = {Takuya Kiyokawa and Mahiro Muta and Weiwei Wan and Kensuke Harada},
    title = {Task-Difficulty-Aware Efficient Object Arrangement Leveraging Tossing Motions},
    booktitle = {Proceedings of IEEE International Conference on Robotic Computing (IRC)},
    pages = {170--173},
    year = {2024}
    }
    
  19. Alberto Bacchin, Leonardo Barcellona, Matteo Terreran, Stefano Ghidoni, Emanuele Menegatti, Takuya Kiyokawa:
    ''WasteGAN: Data Augmentation for Robotic Waste Sorting through Generative Adversarial Networks,''
    in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 5080-5087, Abu Dhabi, UAE, October 2024. arXiv DOI BibTex
    Cite
    @inproceedings{Bacchin2024,
    author = {Alberto Bacchin and Leonardo Barcellona and Matteo Terreran and Stefano Ghidoni and Emanuele Menegatti and Takuya Kiyokawa},
    title = {WasteGAN: Data Augmentation for Robotic Waste Sorting through Generative Adversarial Networks},
    booktitle = {Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
    pages = {5080--5087},
    year = {2024}
    }
  20. Takuya Kiyokawa, Ismael Rodriguez, Korbinian Nottensteiner, Peter Lehner, Thomas Eiband, Maximo A. Roa, and Kensuke Harada:
    ''CAD-Informed Uncertainty-Aware Sequence and Motion Planning for Robotic Assembly,''
    in Proceedings of IEEE International Conference on Automation Science and Engineering (CASE), pp. 418-425, Bari, Italy, August 2024. DOI BibTex
    Cite
    @inproceedings{Kiyokawa2024seqgen,
    author = {Takuya Kiyokawa and Ismael Rodriguez and Korbinian Nottensteiner and Peter Lehner and Thomas Eiband and Maximo A. Roa and Kensuke Harada},
    title = {CAD-Informed Uncertainty-Aware Sequence and Motion Planning for Robotic Assembly},
    booktitle = {Proceedings of IEEE International Conference on Automation Science and Engineering (CASE)},
    pages = {418--425},
    year = {2024}
    }
  21. Shusei Nagato, Tomohiro Motoda, Takao Nishi, Damien Petit, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:
    ''Probabilistic Slide-Support Manipulation Planning in Clutter,''
    in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 1016-1022, Detroit (MI), US, October 2023. arXiv DOI BibTex
    Cite
    @inproceedings{Nagato2023,
    author = {Shusei Nagato and Tomohiro Motoda and Takao Nishi and Damien Petit and Takuya Kiyokawa and Weiwei Wan and Kensuke Harada},
    title = {Probabilistic Slide-Support Manipulation Planning in Clutter},
    booktitle = {Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
    pages = {1016--1022},
    year = {2023}
    }
  22. Kazuki Iwao, Takao Nishi, Takuya Kiyokawa, Damien Petit, Weiwei Wan, and Kensuke Harada:
    ''Planning Dense Object Packing by Pushing Objects,''
    in Proceedings of IEEE International Conference on Automation Science and Engineering (CASE), pp. 1-8, Auckland, New Zealand, August 2023. TechRxiv DOI BibTex
    Cite
    @inproceedings{Iwao2023,
    author = {Kazuki Iwao and Takao Nishi and Takuya Kiyokawa and Damien Petit and Weiwei Wan and Kensuke Harada},
    title = {Planning Dense Object Packing by Pushing Objects},
    booktitle = {Proceedings of IEEE International Conference on Automation Science and Engineering (CASE)},
    pages = {1--8},
    year = {2023}
    }
    
  23. Kota Takata, Takuya Kiyokawa, Ixchel G Ramirez-Alpizar, Natsuki Yamanobe, Weiwei Wan, and Kensuke Harada:
    ''Efficient Task/Motion Planning for a Dual-arm Robot from Language Instructions and Cooking Images,''
    in Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 12058-12065, Kyoto, Japan, October 2022. DOI BibTex
    Cite
    @inproceedings{Takata2022iros,
    author = {Kota Takata and Takuya Kiyokawa and Ixchel G Ramirez-Alpizar and Natsuki Yamanobe and Weiwei Wan and Kensuke Harada},
    title = {Efficient Task/Motion Planning for a Dual-arm Robot from Language Instructions and Cooking Images},
    booktitle = {Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
    pages = {12058--12065},
    year = {2022}
    }
  24. Tatsuya Sakuma, Takuya Kiyokawa, Jun Takamatsu, Takahiro Wada, and Tsukasa Ogasawara:
    ''Soft-Jig: A Flexible Sensing Jig for Simultaneously Fixing and Estimating Orientation of Assembly Parts,''
    in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), pp. 10945-10950, Philadelphia (PA), US, May 2022. DOI arXiv BibTex
    Cite
    @inproceedings{Sakuma2022,
    author = {Tatsuya Sakuma and Takuya Kiyokawa and Jun Takamatsu and Takahiro Wada and Tsukasa Ogasawara},
    title = {Soft-Jig: A Flexible Sensing Jig for Simultaneously Fixing and Estimating Orientation of Assembly Parts},
    booktitle = {Proceedings of IEEE International Conference on Robotics and Automation (ICRA)},
    pages = {10945--10950},
    year = {2022}
    }
  25. Takuya Kiyokawa, Tatsuya Sakuma, Jun Takamatsu and Tsukasa Ogasawara:
    ''Soft-Jig-Driven Assembly Operations,''
    in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), pp. 3466-3472, Online, June 2021
    (IEEE RAS Japan Joint Chapter Young Award). DOI arXiv YouTube BibTex
    Cite
    @inproceedings{Kiyokawa2021softjig,
    author = {Takuya Kiyokawa and Tatsuya Sakuma and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Soft-Jig-Driven Assembly Operations},
    booktitle = {Proceedings of IEEE International Conference on Robotics and Automation (ICRA)},
    pages = {3466--3472},
    year = {2021}
    }
  26. Takuya Kiyokawa, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Assembly Sequences Based on Multiple Criteria Against Products with Deformable Parts,''
    in Proceedings of IEEE International Conference on Robotics and Automation (ICRA), pp. 975-981, Online, June 2021. DOI arXiv YouTube BibTex
    Cite
    @inproceedings{Kiyokawa2021seqgen,
    author = {Takuya Kiyokawa and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Assembly Sequences Based on Multiple Criteria Against Products with Deformable Parts},
    booktitle = {Proceedings of IEEE International Conference on Robotics and Automation (ICRA)},
    pages = {975--981},
    year = {2021}
    }
  27. Naoki Wake, Riku Arakawa, Iori Yanokura, Takuya Kiyokawa, Kazuhiro Sasabuchi, Jun Takamatsu, and Katsushi Ikeuchi:
    ''A Learning-from-Observation Framework: One-Shot Robot Teaching for Grasp-Manipulation-Release Household Operations,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 461-466, Online, January 2021
    (SICE International Young Authors Award (SIYA)). arXiv DOI BibTex
    Cite
    @inproceedings{Wake2021,
    author = {Naoki Wake and Riku Arakawa and Iori Yanokura and Takuya Kiyokawa and Kazuhiro Sasabuchi and Jun Takamatsu and Katsushi Ikeuchi},
    title = {A Learning-from-Observation Framework: One-Shot Robot Teaching for Grasp-Manipulation-Release Household Operations},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {461--466},
    year = {2021}
    }
  28. Hiroki Katayama, Takuya Kiyokawa, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Azimuth Angle Estimation Based on Sound Wave Reflection for Mirrors and Transparent Objects,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 40-45, Online, January 2021. DOI BibTex
    Cite
    @inproceedings{Katayama2021,
    author = {Hiroki Katayama and Takuya Kiyokawa and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Azimuth Angle Estimation Based on Sound Wave Reflection for Mirrors and Transparent Objects},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {40--45},
    year = {2021}
    }
  29. Naoki Shirakura, Takuya Kiyokawa, Hikaru Kumamoto, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Semi-automatic Collection of Marine Debris by Collaborating UAV and UUV,''
    in Proceedings of IEEE International Conference on Robotic Computing (IRC), pp. 412-413, Online, November 2020. DOI BibTex
    Cite
    @inproceedings{Shirakura2020,
    author = {Naoki Shirakura and Takuya Kiyokawa and Hikaru Kumamoto and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Semi-automatic Collection of Marine Debris by Collaborating {UAV} and {UUV}},
    booktitle = {Proceedings of IEEE International Conference on Robotic Computing (IRC)},
    pages = {412--413},
    year = {2020}
    }
  30. Kento Tariki, Takuya Kiyokawa, Gustavo Alfonso Garcia Ricardez, Jun Takamatsu, and Tsukasa Ogasawara:
    ''3D Model-Based Assembly Sequence Optimization Using Insertionable Properties of Parts,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 1400-1405, Honolulu, Hawaii, US, January 2020. DOI BibTex
    Cite
    @inproceedings{Tariki2020sii,
    author = {Kento Tariki and Takuya Kiyokawa and Gustavo Alfonso Garcia Ricardez and Jun Takamatsu and Tsukasa Ogasawara},
    title = {3D Model-Based Assembly Sequence Optimization using Insertionable Properties of Parts},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {1400--1405},
    year = {2020}
    }
  31. Kento Tariki, Takuya Kiyokawa, Tomoki Nagatani, Jun Takamatsu, and Tsukasa Ogasawara:
    ''3D Model-Based Non-interference Assembly Sequence Generation for Products with a Large Number of Parts,''
    in Proceedings of IEEE International Conference on Cybernetics and Intelligent Systems and IEEE International Conference on Robotics, Automation and Mechatronics (CIS-RAM),
    pp. 142-147, Bangkok, Thailand, November 2019. DOI BibTex
    Cite
    @inproceedings{Tariki2019cis-ram,
    author = {Kento Tariki and Takuya Kiyokawa and Tomoki Nagatani and Jun Takamatsu and Tsukasa Ogasawara},
    title = {3D Model-Based Non-interference Assembly Sequence Generation for Products with a Large Number of Parts},
    booktitle = {Proceedings of IEEE International Conference on Cybernetics and Intelligent Systems and IEEE Conference on Robotics, Automation and Mechatronics (CIS-RAM)},
    pages = {142--147},
    year = {2019}
    }
  32. Yuto Tsuchiya, Takuya Kiyokawa, Gustavo Alfonso Garcia Ricardez, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Pouring from Deformable Containers Using Dual-Arm Manipulation and Tactile Sensing,''
    in Proceedings of IEEE International Conference on Robotic Computing (IRC), pp. 357-362, Naples, Italy, February 2019. DOI BibTex
    Cite
    @inproceedings{Tsuchiya2019irc,
    author = {Yuto Tsuchiya and Takuya Kiyokawa and Gustavo Alfonso Garcia Ricardez and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Pouring from Deformable Containers Using Dual-Arm Manipulation and Tactile Sensing},
    booktitle = {Proceedings of IEEE International Conference on Robotic Computing (IRC)},
    pages = {357--362},
    year = {2019}
    }
  33. Takuya Kiyokawa, Ming Ding, Gustavo Alfonso Garcia Ricardez, Jun Takamatsu, and Tsukasa Ogasawara:
    ''Generation of a Tactile-Based Pouring Motion Using Fingertip Force Sensors,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 669-674, Paris, France, January 2019. DOI BibTex
    Cite
    @inproceedings{Kiyokawa2019sii,
    author = {Takuya Kiyokawa and Ming Ding and Gustavo Alfonso Garcia Ricardez and Jun Takamatsu and Tsukasa Ogasawara},
    title = {Generation of a Tactile-based Pouring Motion Using Fingertip Force Sensors},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {669--674},
    year = {2019}
    }
  34. Takuya Kiyokawa, Kousei Nojiri, Hirohumi Ohtsuka, and Youji Okayama:
    ''Estimation of Kinematics Parameters Dependent on Pronation Supination for Modeling Forearm Skeletal System Based on CT Images,''
    in Proceedings of IEEE/SICE International Symposium on System Integration (SII), pp. 422-427, Nagoya, Japan, December 2015. DOI BibTex
    Cite
    @inproceedings{Kiyokawa2015,
    author = {Takuya Kiyokawa and Kousei Nojiri and Hirohumi Ohtsuka and Youji Okayama},
    title = {Estimation of Kinematics Parameters Dependent on Pronation Supination for Modeling Forearm Skeletal System Based on {CT} Images},
    booktitle = {Proceedings of IEEE/SICE International Symposium on System Integration (SII)},
    pages = {422--427},
    year = {2015}
    }
    
  35. Kousei Nojiri, Takuya Kiyokawa, and Yoji Okayama:
    ''Forearm Skeleton Modeling for Pro-/supination Movement Using CT Image Measurement,''
    in Proceedings of IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), pp. 860-865, Busan, Korea, July 2015. DOI BibTex
    Cite
    @inproceedings{Nojiri2015,
    author = {Kousei Nojiri and Takuya Kiyokawa and Yoji Okayama},
    title = {Forearm Skeleton Modeling for Pro-/supination Movement Using {CT} Image Measurement},
    booktitle = {Proceedings of IEEE International Conference on Advanced Intelligent Mechatronics (AIM)},
    pages = {860--865},
    year = {2015}
    }
    

Preprints

2
  1. Nadeen Elhadad, Takuya Kiyokawa, and Kensuke Harada:
    ''Force-Driven Hook Disassembly via Constraint-Aware Object-Centric Reinforcement Learning,''
    arXiv:2610.38513 [cs], Oct. 2026. arXiv BibTex
    Cite
    @article{Nadeen2026tase,
    author = {Nadeen Elhadad and Takuya Kiyokawa and Kensuke Harada},
    title = {Force-Driven Hook Disassembly via Constraint-Aware Object-Centric Reinforcement Learning},
    journal = {CoRR},
    volume = {abs/2610.38513},
    month = Oct,
    year = {2026}
    }
    
  2. Haohui Pan, Takuya Kiyokawa, and Kensuke Harada:
    ''Planning a Shared Modular Fixture Layout Across Robotic Disassembly Stages,''
    arXiv:2608.27151 [cs], Aug. 2026. arXiv BibTex
    Cite
    @article{Pan2026tase,
    author = {Haohui Pan and Takuya Kiyokawa and Kensuke Harada},
    title = {Planning a Shared Modular Fixture Layout Across Robotic Disassembly Stages},
    journal = {CoRR},
    volume = {abs/2608.27151},
    month = {Aug},
    year = {2026}
    }

Journals (in Japanese)

8
  1. 清川 拓哉, 吉本 幸太郎, 高松 淳:
    ''密集する混合産業廃棄物の自動仕分けロボットの構成法,''
    日本ロボット学会誌, vol.41, no.7, pp. 651-654, 2023. (RSJ2022にて発表) DOI BibTex
    Cite
    @article{Kiyokawa2023rsj,
    author = {{清川拓哉} and {吉本幸太郎} and {高松淳}},
    title = {密集する混合産業廃棄物の自動仕分けロボットの構成法},
    journal = {日本ロボット学会誌},
    volume = {41},
    number = {7},
    pages = {651--654},
    year = {2023}
    }
    
  2. 陳 浩, 清川 拓哉, 胡 正涛, 万 偉偉, 原田 研介:
    ''把持物体のオントロジーを用いた未知物体の把持,''
    日本ロボット学会誌, vol.41, no.7, pp. 643-646, 2023. (RSJ2022にて発表) DOI BibTex
    Cite
    @article{Chen2023,
    author = {{陳浩} and {清川拓哉} and {胡正涛} and {万偉偉} and {原田研介}},
    title = {把持物体のオントロジーを用いた未知物体の把持},
    journal = {日本ロボット学会誌},
    volume = {41},
    number = {7},
    pages = {643--646},
    year = {2023}
    }
    
  3. 山本 純也, 東 和樹, 小山 佳祐, 清川 拓哉, 万 偉偉, 原田 研介:
    ''シナジー切り替え可能な指型ウェアラブルアシストロボット -複数指との協調操作の実現-,''
    日本ロボット学会誌, vol.41, no.6, pp. 569-572, 2023. (RSJ2022にて発表) DOI BibTex
    Cite
    @article{Yamamoto2023,
    author = {{山本純也} and {東和樹} and {小山佳祐} and {清川拓哉} and {万偉偉} and {原田研介}},
    title = {シナジー切り替え可能な指型ウェアラブルアシストロボット -複数指との協調操作の実現-},
    journal = {日本ロボット学会誌},
    volume = {41},
    number = {6},
    pages = {569--572},
    year = {2023}
    }
    
  4. 東 和樹, 小山 佳祐, 小澤 隆太, 永田 和之, 万 偉偉, 清川 拓哉, 原田 研介:
    ''多様な物体操作を可能にする流体ネットワークを用いたシナジーハンド,''
    日本ロボット学会誌, vol.40, no.7, pp. 635-638, 2022. (RSJ2021にて発表) DOI BibTex
    Cite
    @article{Higashi2022,
    author = {{東和樹} and {小山佳祐} and {小澤隆太} and {永田和之} and {万偉偉} and {清川拓哉} and {原田研介}},
    title = {多様な物体操作を可能にする流体ネットワークを用いたシナジーハンド},
    journal = {日本ロボット学会誌},
    volume = {40},
    number = {7},
    pages = {635--638},
    year = {2022}
    }
    
  5. 吉本 幸太郎, 清川 拓哉, 高松 淳, 和田 隆広, 小笠原 司:
    ''リサイクルロボットのための熱画像による密集した容器包装廃棄物の分類,''
    日本ロボット学会誌, vol.40, no.6, pp. 538-541, 2022. (RSJ2021にて発表) DOI BibTex
    Cite
    @article{Yoshimoto2022,
    author = {{吉本幸太郎} and {清川拓哉} and {高松淳} and {和田隆広} and {小笠原司}},
    title = {リサイクルロボットのための熱画像による密集した容器包装廃棄物の分類},
    journal = {日本ロボット学会誌},
    volume = {40},
    number = {6},
    pages = {538--541},
    year = {2022}
    }
    
  6. 清川 拓哉, 佐久間 達也, 高松 淳, 小笠原 司:
    ''組立部品の形状と挙動に応じて変形する柔軟治具,''
    日本ロボット学会誌, vol.39, no. 3, pp. 279-282, 2021. (RSJ2020にて発表) DOI BibTex
    Cite
    @article{Kiyokawa2021rsj-softjig,
    author = {{清川拓哉} and {佐久間達也} and {高松淳} and {小笠原司}},
    title = {組立部品の形状と挙動に応じて変形する柔軟治具},
    journal = {日本ロボット学会誌},
    volume = {39},
    number = {3},
    pages = {279--282},
    year = {2021}
    }
    
  7. 清川 拓哉, 田力 健人, 高松 淳, 小笠原 司:
    ''変形物体を含む製品の組立作業計画を考慮した3次元CADモデルからの組立順序生成,''
    日本ロボット学会誌, vol.39, no. 2, pp. 169-172, 2021. (RSJ2020にて発表) DOI BibTex
    Cite
    @article{Kiyokawa2021rsj-seqgen,
    author = {{清川拓哉} and {田力健人} and {高松淳} and {小笠原司}},
    title = {変形物体を含む製品の組立作業計画を考慮した3次元CADモデルからの組立順序生成},
    journal = {日本ロボット学会誌},
    volume = {39},
    number = {2},
    pages = {169--172},
    year = {2021}
    }
    
  8. 野尻 紘聖, 清川 拓哉, 大塚 弘文, 岡山 洋二:
    ''粒子群最適化に基づく前腕骨格モデルの剛性パラメータ同定手法,''
    人間工学, vol. 52, no. 1, pp. 30-39, 2016. DOI BibTex
    Cite
    @article{Nojiri2016,
    author = {{野尻紘聖} and {清川拓哉} and {大塚弘文} and {岡山洋二}},
    title = {粒子群最適化に基づく前腕骨格モデルの剛性パラメータ同定手法},
    journal = {人間工学},
    volume = {52},
    number = {1},
    pages = {30-39},
    year = {2016}
    }
    

Domestic Conferences (in Japanese)

108
  1. 清川 拓哉, 設樂 哲弥, 東 和樹, 原田 研介:
    ''生物規範の探索制約に基づくモジュラーマニピュレーションロボットのアクチュエータ配置と移動・操作方策生成,''
    第27回 計測自動制御学会システムインテグレーション部門講演会(SI2026), 1F2-02, 大阪, 12月, 2026.
  2. 清川 拓哉, 佐向 元, 原田 研介:
    ''保持と部品分離のシナジーを考慮した把持対提示を用いた上体ヒューマノイドによる非破壊分解の遠隔操作に基づく模倣学習,''
    第27回 計測自動制御学会システムインテグレーション部門講演会(SI2026), 1E8-01, 大阪, 12月, 2026.
  3. 潘 昊輝, 清川 拓哉, 原田 研介:
    ''分解工程全体で再配置を要しないモジュール式柔軟治具の配置計画,''
    第27回 計測自動制御学会システムインテグレーション部門講演会(SI2026), 1F2-03, 大阪, 12月, 2026.
  4. 佐向 元, 清川 拓哉, 原田 研介:
    ''嵌合部品の非破壊分解に向けた遠隔操作システムの模倣学習データ収集への適用,''
    第27回 計測自動制御学会システムインテグレーション部門講演会(SI2026), 1E8-02, 大阪, 12月, 2026.
  5. 藤本 郁人, 清川 拓哉, 万 偉偉, 原田 研介:
    ''VLMと論理的評価による柔軟かつ正確な紐結び作業計画と実機検証,''
    第44回 日本ロボット学会学術講演会(RSJ2026), 2H3-02, 石川, 9月, 2026
  6. Nadeen Elhadad, Takuya Kiyokawa, Kensuke Harada:
    ''Force-Driven Robotic Hook Disassembly via Constraint-Aware Object-Centric Reinforcement Learning,''
    ロボティクス・メカトロニクス講演会2026(ROBOMECH2026), 1P1-A01, 福岡, 6月, 2026.
  7. 清川 拓哉, 設樂 哲弥, 千原 健之介, 原田 研介:
    ''脚型モジュラーロボットの歩行の多目的最適化における哺乳類歩容に基づく探索制約の効果,''
    ロボティクス・メカトロニクス講演会2026(ROBOMECH2026), 1P1-P09, 福岡, 6月, 2026.
  8. 東 和樹, 清川 拓哉, 東森 充:
    ''多指ロボットハンドにおける関節機能の自己構成法の提案,''
    ロボティクス・メカトロニクス講演会2026(ROBOMECH2026), 1P1-P07, 福岡, 6月, 2026.
  9. 千原 健之介, 清川 拓哉, 原田 研介:
    ''簡易脱着関節を有する脚型モジュラーロボットのための関節負荷低減と移動性能を両立する歩行生成,''
    ロボティクス・メカトロニクス講演会2026(ROBOMECH2026), 1P1-P04, 福岡, 6月, 2026.
  10. 清川 拓哉, 石倉 智貴, 濱田 真吾, 松田 源一郎, 原田 研介:
    ''ロボット分解におけるシステム再構成性が作業効率に及ぼす影響,''
    ロボティクス・メカトロニクス講演会2026(ROBOMECH2026), 1P1-O12, 福岡, 6月, 2026.
  11. 石川 智大, 原田 研介, Vitor Hideyo Isume, 清川 拓哉, 万 偉偉:
    ''VLMを用いた作業用ハンドの自動設計,''
    ロボティクス・メカトロニクス講演会2026(ROBOMECH2026), 1P1-N09, 福岡, 6月, 2026.
  12. 藤本 郁人, 奥村 亮, 西澤 克彦, 清川 拓哉, 万 偉偉, 原田 研介:
    ''VLMとFOONを用いた紐結びの長期作業計画,''
    ロボティクス・メカトロニクス講演会2026(ROBOMECH2026), 1A1-U02, 福岡, 6月, 2026.
  13. Radwa Ali, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada:
    ''Retrieval-Augmented Multi-Agent LLM Framework for Intelligent Assembly Process Design and Optimization,''
    第26回 計測自動制御学会システムインテグレーション部門講演会(SI2025), 1E7-03, 広島, 12月, 2025.
  14. Hao Chen, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada:
    ''Task-Oriented Grasping of Unseen Objects via Ontological Reasoning and Template-Based Planning,''
    第26回 計測自動制御学会システムインテグレーション部門講演会(SI2025), 1C3-13, 広島, 12月, 2025.
  15. Mahfudz Maskur, Takuya Kiyokawa, Kensuke Harada:
    ''Design of a 3D-Printed Servo-Driven Module Changer for Reconfigurable Robots,''
    第26回 計測自動制御学会システムインテグレーション部門講演会(SI2025), 1C7-08, 広島, 12月, 2025.
  16. 清川 拓哉, 石倉 智貴, 濱田 真吾, 松田 源一郎, 原田 研介:
    ''ロボットによる分解作業計画に基づく構成部品の影響度推定,''
    第26回 計測自動制御学会システムインテグレーション部門講演会(SI2025), 2C3-02, 広島, 12月, 2025.
    (SI2025 優秀講演賞).
  17. 清川 拓哉, 岩本 拓也, 野口 悠人, 武田 信和, 原田 研介:
    ''複雑環境下での重量物操作のための関節負荷最小化経路計画,''
    第26回 計測自動制御学会システムインテグレーション部門講演会(SI2025), 1B7-04, 広島, 12月, 2025.
    (SI2025 優秀講演賞).
  18. Yuan Gao, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada:
    ''Data-Efficient Disassembly Sequence Planning via Learning Precedence Relations from Multiple Solutions,''
    第43回 日本ロボット学会学術講演会(RSJ2025), 2F2-05, 東京, 9月, 2025.
  19. Vitor Hideyo Isume, Takuya Kiyokawa, Natsuki Yamanobe, Yukiyasu Domae, Weiwei Wan, Kensuke Harada:
    ''Craft Assembly Plans in Combination with LLMs and Physics Simulation,''
    第43回 日本ロボット学会学術講演会(RSJ2025), 2F2-03, 東京, 9月, 2025.
  20. Radwa Ali, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada:
    ''An LLM-based Multi-Agent Framework for Robotic Workcell Layout Configurator,''
    第43回 日本ロボット学会学術講演会(RSJ2025), 2C2-04, 東京, 9月, 2025.
  21. Zhenting Wang, Takuya Kiyokawa, Natsuki Yamanobe, Weiwei Wan, Kensuke Harada:
    ''Task Allocation for Human-Robot Collaborative Assembly by Predicting Human-Related Complexity,''
    第43回 日本ロボット学会学術講演会(RSJ2025), 1F2-01, 東京, 9月, 2025
    (RSJ2025 International Session Best Presentation Award Finalist).
  22. 松山 尚恭, 万 偉偉, 小山 佳祐, 清川 拓哉, 原田 研介:
    ''接触状態を考慮したソフトフィンガーの三次元形状推定,''
    ロボティクス・メカトロニクス講演会2025(ROBOMECH2025), 2P1-Q05, 山形, 6月, 2025.
  23. Mahfudz Maskur, Takuya Kiyokawa, Kensuke Harada, Tomoki Ishikura, Naoya Miyaji, Genichiro Matsuda:
    ''GNN-Based Surrogate Model for Disassembly Manipulation Feasibility Evaluation from Semantic Graph Network,''
    ロボティクス・メカトロニクス講演会2025(ROBOMECH2025), 1A1-M01, 山形, 6月, 2025.
  24. 山田 大夢, 奥村 亮, 清川 拓哉, 藤本 郁人, 万 偉偉, 原田 研介:
    ''柔軟ひも状物体の把持に向けた視触覚画像生成モデルの構築,''
    ロボティクス・メカトロニクス講演会2025(ROBOMECH2025), 1A2-F06, 山形, 6月, 2025.
  25. 西村 樹希, 万 偉偉, 清川 拓哉, 原田 研介:
    ''移動ロボットを用いた密集した大型物体への押し操作,''
    ロボティクス・メカトロニクス講演会2025(ROBOMECH2025), 1A2-E06, 山形, 6月, 2025.
  26. 清川 拓哉, 東 和樹, 原田 研介:
    ''作業適応型モジュラーロボットのための簡易脱着接合部と自己再構成動作の実現,''
    ロボティクス・メカトロニクス講演会2025(ROBOMECH2025), 1A1-K08, 山形, 6月, 2025.
  27. 佐向 元, 清川 拓哉, 原田 研介, 石倉 智貴, 宮地 直也, 松田 源一郎:
    ''アフォーダンス提示による嵌合部品分解の効率的な実演教示,''
    ロボティクス・メカトロニクス講演会2025(ROBOMECH2025), 1A1-D01, 山形, 6月, 2025.
  28. 清川 拓哉, 石倉 智貴, 宮地 直也,松田 源一郎,原田 研介:
    ''複数ロボットによる拘束構造の分解作業計画 - 拘束を考慮した順序とタスクの階層的最適化 -,''
    第30回ロボティクスシンポジア, 愛媛, 3月, 2025. (査読あり)
  29. Hao Chen, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada:
    ''Vision-Based Dynamic Grasping of Moving Objects in Cluttered Scenes,''
    第25回 計測自動制御学会システムインテグレーション部門講演会(SI2024), 1B4-08, 岩手, 12月, 2024.
  30. Radwa Ali, Zhengtao Hu, Takuya Kiyokawa, Weiwei Wan, Tatsushi Nishi, Kensuke Harada:
    ''Optimizing Robotic Workcell Layouts: Integrating Grasp Pose Analysis with Task and Motion Planning,''
    第25回 計測自動制御学会システムインテグレーション部門講演会(SI2024), 1B2-02, 岩手, 12月, 2024.
  31. 竹林 龍之介, 清川 拓哉, 原田 研介, 石倉 智貴, 宮地 直也, 松田 源一郎:
    ''分解作業における固定物体の姿勢保持が可能なシェル型柔軟治具,''
    第25回 計測自動制御学会システムインテグレーション部門講演会(SI2024), 1B1-08, 岩手, 12月, 2024.
    (SI2024 優秀講演賞).
  32. Vitor Hideyo Isume, Takuya Kiyokawa, Natsuki Yamanobe, Yukiyasu Domae, Weiwei Wan, Kensuke Harada:
    ''Using LLM with Physical Simulation Feedback as a Craft Assembly Planner,''
    第42回 日本ロボット学会学術講演会(RSJ2024), 1G1-01, 大阪, 9月, 2024.
  33. 竹林 龍之介, 清川 拓哉, 万 偉偉, 原田 研介:
    ''グラフネットワークにより検証可能なLLMに基づく料理作業動作計画,''
    第42回 日本ロボット学会学術講演会(RSJ2024), 3D2-08, 大阪, 9月, 2024.
  34. 陳 浩, 清川 拓哉, 万 偉偉, 原田 研介:
    ''Single-view dexterous object grasping under high uncertainty using multi-level similarity matching,''
    第42回 日本ロボット学会学術講演会(RSJ2024), 3B1-02, 大阪, 9月, 2024.
  35. 所 亮太, 東 和樹, 清川 拓哉, 万 偉偉, 原田 研介:
    ''関節付きオブジェクトのためのシナジー自動学習法の提案 ,''
    第42回 日本ロボット学会学術講演会(RSJ2024), 2F3-02, 大阪, 9月, 2024.
  36. Alberto Bacchin, Takuya Kiyokawa, Emanuele Menegatti, Takamitsu Matsubara, Kensuke Harada:
    ''GAN-Based Data Augmentation for Manipulation-Oriented Segmentation of Mixed Industrial Waste Images,''
    ロボティクス・メカトロニクス講演会2024(ROBOMECH2024), 1P2-R01, 宇都宮, 5月, 2024.
  37. 牟田 真尋, 清川 拓哉, 万 偉偉, 原田 研介:
    ''作業難度に基づいてトス動作を活用する陳列作業計画,''
    ロボティクス・メカトロニクス講演会2024(ROBOMECH2024), 1P2-K06, 宇都宮, 5月, 2024.
  38. 長田 瑛綺, 清川 拓哉, 鶴峯 義久, 権 裕煥, 松原 崇充:
    ''視覚情報に基づく移動把持の自己教師あり学習,''
    ロボティクス・メカトロニクス講演会2024(ROBOMECH2024), 1P1-H04, 宇都宮, 5月, 2024.
  39. 山下 智史, 清川 拓哉, 石倉 智貴, 宮地 直也, 松田 源一郎, 万 偉偉, 原田 研介:
    ''異なる操作戦略を要する多様な部品を含む大型家電の分解作業計画,''
    ロボティクス・メカトロニクス講演会2024(ROBOMECH2024), 1P1-A03, 宇都宮, 5月, 2024.
  40. Chenxi Wang, Takuya Kiyokawa, Weiwei Wan, Natsuki Yamanobe, Kensuke Harada:
    ''Vision-based Modelless Assembly from Graphical Instruction Manual,''
    第24回 計測自動制御学会システムインテグレーション部門講演会(SI2023), 3E5-02, 新潟, 12月, 2023.
  41. 田中 寛仁, 都留 将人, 清川 拓哉, 原田 研介:
    ''移動マニピュレータによる大型構造物の塗装計画,''
    第24回 計測自動制御学会システムインテグレーション部門講演会(SI2023), 3A1-15, 新潟, 12月, 2023.
  42. 余 昌志, 陳 浩, 清川 拓哉, 万 偉偉, 原田 研介:
    ''局所形状の類似性評価に基づくオクルージョンのある未知物体の把持生成,''
    第24回 計測自動制御学会システムインテグレーション部門講演会(SI2023), 3A1-14, 新潟, 12月, 2023.
  43. 端井 大貴, 清川 拓哉, 万 偉偉, 原田 研介:
    ''位置と力のハイブリッド制御の学習に基づく複数ステップ包装作業,''
    第24回 計測自動制御学会システムインテグレーション部門講演会(SI2023), 1F5-01, 新潟, 12月, 2023.
    (SI2023 優秀講演賞).
  44. 陳 浩, 清川 拓哉, 胡 正涛, 万 偉偉, 原田 研介:
    ''Similarity-based fast grasp planning of unknown objects on a conveyor belt,''
    第41回 日本ロボット学会学術講演会(RSJ2023), 2E2-05, 仙台, 9月, 2023.
  45. 金本 翔真, 胡 正涛, 清川 拓哉, 万 偉偉, 原田 研介:
    ''インピーダンス制御に基づく遮蔽のある未知対象物の把持計画,''
    第41回 日本ロボット学会学術講演会(RSJ2023), 2E2-04, 仙台, 9月, 2023.
  46. 竹林 龍之介, 清川 拓哉, 万 偉偉, 原田 研介:
    ''ChatGPTと作業グラフを併用した料理作業動作 計画,''
    第41回 日本ロボット学会学術講演会(RSJ2023), 2E1-03, 仙台, 9月, 2023.
  47. 余 博文, 万 偉偉, 小山 佳祐, 清川 拓哉, 原田 研介:
    ''リニアガイドを用いた高荷重2指平行グリッパー,''
    第41回 日本ロボット学会学術講演会(RSJ2023), 1E2-04, 仙台, 9月, 2023.
  48. 清川 拓哉, 原田 研介, 石倉 智貴, 宮地 直也, 松田 源一郎:
    ''ヒトとロボットの効率的な分解・解体作業を目指した進化型多数目的最適化による組立製品モデルからの順序生成,''
    ロボティクス・メカトロニクス講演会2023(ROBOMECH2023), 2P1-B10, 名古屋, 6月, 2023.
  49. Vitor Hideyo Isume, Takuya Kiyokawa, Natsuki Yamanobe, Weiwei Wan, Kensuke Harada:
    ''Craft Assembly Task: Improving Primitive Shape Generation from RGB Image via Mesh Templates,''
    ロボティクス・メカトロニクス講演会2023(ROBOMECH2023), 2P1-E05, 名古屋, 6月, 2023.
  50. 端井 大貴, 清川 拓哉, 万 偉偉, 原田 研介:
    ''人の動作教示に基づく複数動作ステップからなる包装作業の学習,''
    ロボティクス・メカトロニクス講演会2023(ROBOMECH2023), 2A2-D26, 名古屋, 6月, 2023.
  51. 所 亮太, 小山 佳祐, 清川 拓哉, 万 偉偉, 原田 研介:
    ''剛性可変な内骨格を備えたパウチモータの開発,''
    ロボティクス・メカトロニクス講演会2023(ROBOMECH2023), 2A1-D22, 名古屋, 6月, 2023.
  52. 瀧谷 悠乃, 小山 佳祐, 清川 拓哉, 万 偉偉, 原田 研介:
    ''形状記憶樹脂を用いた剛性可変折り紙アクチュエータ,''
    ロボティクス・メカトロニクス講演会2023(ROBOMECH2023), 2P2-E11, 名古屋, 6月, 2023.
  53. 平尾 友佑, 万 偉偉, 清川 拓哉, 小山 佳祐, 原田 研介:
    ''手先にカメラを有する二台の移動型マニピュレータの遠隔操作,''
    ロボティクス・メカトロニクス講演会2023(ROBOMECH2023), 2P1-E04, 名古屋, 6月, 2023.
  54. 長門 秀征, 元田 智大, 西 卓郎, 清川 拓哉, 万 偉偉, 原田 研介:
    ''物体の状態遷移予測を用いた山積みからの双腕引き出し計画,''
    第23回 計測自動制御学会システムインテグレーション部門講演会(SI2022), 3P2-H05, 千葉, 12月, 2022.
    (SI2022 優秀講演賞).
  55. 北村 凌, 小山 佳祐, 清川 拓哉, 万 偉偉, 原田 研介:
    ''ビジョンセンサレスばら積みピッキングの自動パラメータチューニング,''
    第23回 計測自動制御学会システムインテグレーション部門講演会(SI2022), 3P2-H03, 千葉, 12月, 2022.
    (SI2022 優秀講演賞).
  56. 中村 祐賀, 万 偉偉, 清川 拓哉, 原田 研介:
    ''強化学習による非把持持ち上げ動作の生成,''
    第23回 計測自動制御学会システムインテグレーション部門講演会(SI2022), 2A2-A14, 千葉, 12月, 2022.
    (SI2022 優秀講演賞).
  57. 田中 康平, 小山 佳祐, 清川 拓哉, 万 偉偉, 原田 研介:
    ''小型・低摩擦アクチュエータ”MagLinkage II”を用いた外界センサレスでのカードの高速把持,''
    第23回 計測自動制御学会システムインテグレーション部門講演会(SI2022), 1P3-H17, 千葉, 12月, 2022.
  58. 巌 和貴, 西 卓郎, 清川 拓哉, 万 偉偉, 原田 研介:
    ''複数対象物の同時プッシングを用いた箱詰め作業の計画,''
    第23回 計測自動制御学会システムインテグレーション部門講演会(SI2022), 1A2-A13, 千葉, 12月, 2022.
  59. 清川 拓哉, 胡 正涛, 佐久間 達也, 万 偉偉, 高松 淳, 原田 研介:
    ''再把持のためのジャミンググリッパ模倣型の柔軟治具,''
    第40回 日本ロボット学会学術講演会(RSJ2022), 4K2-06, 東京, 9月, 2022.
  60. 陳 浩, 清川 拓哉, 胡 正涛, 万 偉偉, 原田 研介:
    ''把持物体のオントロジーを用いた未知物体の把持,''
    第40回 日本ロボット学会学術講演会(RSJ2022), 3F1-01, 東京, 9月, 2022.
  61. Muhammad Ahmad Sajid, Takuya Kiyokawa, Zhengtao Hu, Weiwei Wan, Kensuke Harada:
    ''Non-Newtonian based Soft Fixture for an Assembly Task,''
    第40回 日本ロボット学会学術講演会(RSJ2022), 2J1-05, 東京, 9月, 2022.
  62. 清川 拓哉, 吉本 幸太郎, 高松 淳:
    ''密集する混合産業廃棄物の自動仕分けロボットの構成法,''
    第40回 日本ロボット学会学術講演会(RSJ2022), 4C1-07, 東京, 9月, 2022.
  63. 山本 純也, 東 和樹, 小山 佳祐, 清川 拓哉, 万 偉偉, 原田 研介:
    ''シナジー切り替え可能な指型ウェアラブルアシストロボット,''
    第40回 日本ロボット学会学術講演会(RSJ2022), 4D3-05, 東京, 9月, 2022.
  64. Zhenting Wang, Natsuki Yamanobe, Takuya Kiyokawa, Ixchel G. Ramirez-Alpizar, Issei Sera, Weiwei Wan, Kensuke Harada:
    ''Robot Assembly Planning using Symbol and Speech Bubble Information on Graphical Instruction Manuals,''
    ロボティクス・メカトロニクス講演会2022(ROBOMECH2022), 2A2-N03, 札幌, 6月, 2022.
  65. 平尾 友佑, 万 偉偉, 清川 拓哉, 小山 佳祐, 原田 研介:
    ''二台の移動マニピュレータを利用した双腕テレオペレーション,''
    ロボティクス・メカトロニクス講演会2022(ROBOMECH2022), 2P1-E07, 札幌, 6月, 2022.
  66. 黒田 和暉, ダミアン・ペティ, 清川 拓哉, 小山 佳祐, 万 偉偉, 原田 研介:
    ''Mixed Realityを用いた仮想環境上での組立作業の教示,''
    ロボティクス・メカトロニクス講演会2022(ROBOMECH2022), 2A2-N07, 札幌, 6月, 2022.
  67. 小林 聖, 小山 佳祐, 清川 拓哉, 万 偉偉, 原田 研介:
    ''高速・高精度近接覚センサフィードバックを用いた非接触ダイレクトティーチング,''
    ロボティクス・メカトロニクス講演会2022(ROBOMECH2022), 2A2-J03, 札幌, 6月, 2022.
  68. 瀧谷 悠乃, 小山 佳祐, 清川 拓哉, 万 偉偉, 原田 研介:
    ''形状記憶樹脂HUMOFITを用いた箸操作訓練のためのウェアラブルデバイス,''
    ロボティクス・メカトロニクス講演会2022(ROBOMECH2022), 2A2-D03, 札幌, 6月, 2022.
  69. 牟田 真尋, 清川 拓哉, 小山 佳祐, 万 偉偉, 原田 研介:
    ''迅速な箱詰め作業のための投射物の状態を考慮したトス動作の学習,''
    ロボティクス・メカトロニクス講演会2022(ROBOMECH2022), 2A1-O02, 札幌, 6月, 2022.
  70. 東 和樹, 小山 佳祐, 小澤 隆太, 永田 和之, 万 偉偉, 清川 拓哉, 原田 研介:
    ''トルク推定可能な水圧式蛇腹ソフトアクチュエータ,''
    ロボティクス・メカトロニクス講演会2022(ROBOMECH2022), 2A1-M05, 札幌, 6月, 2022.
  71. 田中 康平, 小山 佳祐, 清川 拓哉, 万 偉偉, 原田 研介:
    ''小型・低摩擦アクチュエータ "MagLinkage II"を用いた外界センサレスでのカードの高速把持,''
    ロボティクス・メカトロニクス講演会2022(ROBOMECH2022), 2A1-J06, 札幌, 6月, 2022.
  72. 田中 寛仁, 都留 将人, 清川 拓哉, 小山 佳祐, 万 偉偉, 原田 研介:
    ''移動マニピュレータによる作業のためのARマーカーによる3D-SLAM自己位置の修正,''
    ロボティクス・メカトロニクス講演会2022(ROBOMECH2022), 1A1-G05, 札幌, 6月, 2022.
  73. 小林 聖, 万 偉偉, 清川 拓哉, 小山 佳祐, 原田 研介:
    ''把持物体の3次元形状復元を目的とした最適な次姿勢の探索,''
    第22回 計測自動制御学会システムインテグレーション部門講演会(SI2021), 1D1-01, オンライン, 12月, 2021.
  74. 中津留 健人, 万 偉偉, 清川 拓哉, 小山 佳祐, 原田 研介:
    ''環境との接触を利用した大型重量物のモバイルマニピュレーションの計画と最適化,''
    第22回 計測自動制御学会システムインテグレーション部門講演会(SI2021), 1H2-01, オンライン, 12月, 2021.
    (SI2021 優秀講演賞).
  75. 黒田 和暉, 清川 拓哉, Damien Petit, 小山 佳祐, 万 偉偉, 原田 研介:
    '' Mixed Realityを用いた仮想環境上での組立作業の教示,''
    第22回 計測自動制御学会システムインテグレーション部門講演会(SI2021), 1D2-02, オンライン, 12月, 2021.
  76. 高田 康太, 山野辺 夏樹, ラミレス イクシェル, 清川 拓哉, 小山 佳祐, 万 偉偉, 原田 研介:
    ''言語指示と料理画像を基にしたロボットの作業計画,''
    第22回 計測自動制御学会システムインテグレーション部門講演会(SI2021), 1D3-05, オンライン, 12月, 2021.
  77. Hao Chen, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada:
    ''Vision-Based Novel Object Grasping based on Object-Semantics Matching with Grasp Database,''
    第39回 日本ロボット学会学術講演会(RSJ2021), 1A1-01, オンライン, 9月, 2021
    (RSJ2021 International Session Best Presentation Award Finalist).
  78. 吉本 幸太郎, 清川 拓哉, 高松 淳, 和田 隆広, 小笠原 司:
    ''リサイクルロボットのための熱画像による密集した容器包装廃棄物の分類,''
    第39回 日本ロボット学会学術講演会(RSJ2021), 3F1-05, オンライン, 9月, 2021.
  79. 山村 亮太郎, 吉本 幸太郎, 清川 拓哉, 高松 淳, 和田 隆広:
    ''密集した不定形状物体の均し作業のための箒グリッパの開発,''
    第39回 日本ロボット学会学術講演会(RSJ2021), 1G3-04, オンライン, 9月, 2021.
  80. 東 和樹, 小山 佳祐, 小澤 隆太, 永田 和之, 万 偉偉, 清川 拓哉, 原田 研介:
    ''多様な物体操作を可能にする流体ネットワークを用いたシナジーハンド,''
    第39回 日本ロボット学会学術講演会(RSJ2021), 3F1-02, オンライン, 9月, 2021.
  81. 松岡 尚吾, 万 偉偉, 清川 拓哉, 小山 佳祐, 原田 研介:
    ''視覚・触覚センサを用いた透明物体の把持姿勢推定,''
    第39回 日本ロボット学会学術講演会(RSJ2021), 2F3-03, オンライン, 9月, 2021.
  82. 吉本 幸太郎, 清川 拓哉, 高松 淳, 小笠原 司:
    ''リサイクルロボットのための熱画像を用いた容器包装廃棄物の領域抽出と材料分類,''
    第26回ロボティクスシンポジア, 3A1, オンライン, 3月, 2021. (査読あり)
  83. 清川 拓哉, 龍田 侑弥, 片山 寛基, 高松 淳, 小笠原 司:
    ''ロボットアームを用いたアルミニウム廃材の密集率調整システム,''
    第21回 計測自動制御学会システムインテグレーション部門講演会(SI2020), 1G1-18, オンライン, 12月, 2020.
  84. 龍田 侑弥, 佐久間 達也, 清川 拓哉, 高松 淳, 小笠原 司:
    ''平板廃棄物把持のためのニードル付きジャミング吸着グリッパの開発,''
    第21回 計測自動制御学会システムインテグレーション部門講演会(SI2020), 2E2-07, オンライン, 12月, 2020.
  85. 清川 拓哉, 田力 健人, 高松 淳, 小笠原 司:
    ''変形物体を含む製品の組立作業計画を考慮した3次元CADモデルからの組立順序生成,''
    第38回 日本ロボット学会学術講演会(RSJ2020), 2D3-01, オンライン, 10月, 2020.
  86. 清川 拓哉, 佐久間 達也, 高松 淳, 小笠原 司:
    ''組立部品の形状と挙動に応じて変形する柔軟治具,''
    第38回 日本ロボット学会学術講演会(RSJ2020), 3B2-05, オンライン, 10月, 2020.
  87. 龍田 侑弥, 清川 拓哉, 高松 淳, 小笠原 司:
    ''球状ジャミンググリッパを用いた物体操作 —力制御を必要としない転がし操作—,''
    第38回 日本ロボット学会学術講演会(RSJ2020), 3B2-04, オンライン, 10月, 2020.
  88. 清川 拓哉, 片山 寛基, 高松 淳, 小笠原 司:
    ''Active Vaporによる鏡面と透明物体表面の法線推定,''
    第23回 画像の認識・理解シンポジウム(MIRU2020), OS3-2A-3, オンライン, 8月, 2020. (査読あり, ショート発表)
  89. 清川 拓哉, 高松 淳, 小笠原 司:
    ''包装商品のランダムピッキングシステムのためのパッケージ表面の法線方向と不可視率の自動アノテーション,''
    2020年度 人工知能学会全国大会(第34回)(JSAI2020), 4Rin1-93, オンライン, 6月, 2020. (査読あり)
  90. 清川 拓哉, 高松 淳, 小笠原 司:
    ''容器包装廃棄物を分別するロボットビジョンシステムのための自動学習データセット生成と実環境との差異を考慮した学習,''
    ロボティクス・メカトロニクス講演会2020(ROBOMECH2020), 2P2-J13, オンライン, 5月, 2020.
  91. 清川 拓哉, 友近 圭汰, 高松 淳, 小笠原 司:
    ''ハンドアイカメラ搭載のマニピュレータと回転ステージを用いた陳列商品検出用の学習データセットの自動収集システム,''
    第20回 計測自動制御学会システムインテグレーション部門講演会(SI2019), 1C5-03, 高松, 12月, 2019.
  92. 白倉 尚貴, 熊本 光, 清川 拓哉, 清水 拓海, 高松 淳, 小笠原 司:
    ''水中ドローンによるティーチングプレイバックを用いた浮遊物の半自動回収システム,''
    第20回 計測自動制御学会システムインテグレーション部門講演会(SI2019), 3C5-10, 高松, 12月, 2019.
  93. 清川 拓哉, 高松 淳, 笹渕 一宏, 小笠原 司, 池内克史:
    ''視覚マーカを貼付した物体の観察による回転関節のパラメータ推定,''
    第37回 日本ロボット学会学術講演会(RSJ2019), 3E2-03, 東京, 9月, 2019.
  94. 田力 健人, 清川 拓哉, 永谷 智貴, 高松 淳, 小笠原 司:
    ''部品の3次元モデルのみを用いた部品数の多い製品に対する組立順序の最適化,''
    第37回 日本ロボット学会学術講演会(RSJ2019), 3I1-04, 東京, 9月, 2019.
  95. 片山 寛基, 清川 拓哉, 高松 淳, 小笠原 司:
    ''音波の周波数による反射特性の変化を用いた物体面の法線方向推定の可能性の検証,''
    第37回 日本ロボット学会学術講演会(RSJ2019), 2I2-03, 東京, 9月, 2019.
  96. 清川 拓哉, 友近 圭汰, 高松 淳, 小笠原 司:
    ''Web アプリを用いた多視点画像データセットの効率的な収集手法,''
    第19回 計測自動制御学会システムインテグレーション部門講演会(SI2018), 3D4-12, 大阪, 12月, 2018.
  97. 土屋 裕杜, 清川 拓哉, Gustavo Alfonso Garcia Ricardez, 高松 淳, 小笠原 司:
    ''双腕ロボットを用いた力覚情報に基づく柔軟容器からの注ぎ動作,''
    第19回 計測自動制御学会システムインテグレーション部門講演会(SI2018), 3A2-07, 大阪, 12月, 2018.
  98. 野尻 紘聖, 清川 拓哉, 大塚 弘文, 堀川 悦夫:
    ''複数の指先接触力を計測可能な3軸力覚センサボールの開発,''
    第19回 計測自動制御学会システムインテグレーション部門講演会(SI2018), 1D2-11, 大阪, 12月, 2018.
  99. 北村 勇希, 清川 拓哉, 丁 明, 高松 淳, 小笠原 司:
    ''タッチケアロボットのための温度制御可能な受動機構を有する柔軟指の開発,''
    第36回 日本ロボット学会学術講演会(RSJ2018), 2D1-01, 春日井, 9月, 2018.
  100. 友近 圭汰, 清川 拓哉, 高松 淳, 小笠原 司:
    ''視覚マーカを用いた物体検出のための偏りのない学習データ自動収集システム,''
    ロボティクス・メカトロニクス講演会2018(ROBOMECH2018), 2A2-J18, 北九州, 6月, 2018.
  101. 趙 崇貴, 清川 拓哉, 友近 圭汰, 吉川雅博, 小笠原 司:
    ''前腕形状計測に基づく手の動作認識によるロボットアームの操作,''
    ヒューマンインタフェース学会ヒューマンインタフェースシンポジウム2017, 7D2-2, 大阪, 9月, 2017.
  102. 野尻 紘聖, 清川 拓哉:
    ''モーションキャプチャを用いた前腕回内回外の尺骨挙動推定手法の検討,''
    日本人間工学会 第58回大会, C3-4, 習志野, 6月, 2017.
  103. 清川 拓哉, 野尻 紘聖, 大塚 弘文, 岩田 大助:
    ''前腕骨格のパラレルメカニズムを用いた投球動作時の回旋中心軸ベクトルの推定,''
    シンポジウム:スポーツ工学・ヒューマンダイナミクス2015, A-8, 草津, 10月, 2015.
  104. 清川 拓哉, 野尻 紘聖, 大塚 弘文, 岡山 洋二:
    ''CT画像に基づく前腕骨格モデルの運動学パラメータ推定手法の検討,''
    生体医工学シンポジウム2015, 1A-38, 岡山, 9月, 2015. (査読あり)
  105. 清川 拓哉, 野尻 紘聖, 岡山 洋二:
    ''PSOを用いた前腕骨格モデルの非線形剛性パラメータ推定手法の提案,''
    ロボティクス・メカトロニクス講演会2015(ROBOMECH2015), 1P1-I03, 京都, 5月, 2015.
  106. 清川 拓哉, 野尻 紘聖:
    ''前腕骨格の回内・回外モデルのための剛性パラメータ推定手法に関する考察,''
    第2回 制御部門マルチシンポジウム(MSCS2015), 544-5, 東京, 3月, 2015.
  107. 清川 拓哉, 野尻 紘聖:
    ''粒子群最適化による前腕骨格の回内・回外モデルのパラメータ推定,''
    第15回 計測自動制御学会システムインテグレーション部門講演会(SI2014), 3J3-2, 東京, 12月, 2014.
  108. 清川 拓哉, 野尻 紘聖:
    ''前腕の回旋中心軸推定のため前腕回内・回外の動作分析,''
    電子情報通信学会技術研究報告, vol. 114, no. 261, WIT2014-37, pp. 3-6, 熊本, 10月, 2014. 論文情報

Activity

Grants, awards and contributions

Patents

6
  1. 清川 拓哉, 原田 研介, 石倉 智貴, 松田 源一郎:
    ''分解情報生成方法,''
    (出願中).
  2. 清川 拓哉, 原田 研介, 石倉 智貴, 宮地 直也:
    ''分解情報生成方法,''
    PCT国際出願 PCT/JP2025/013404, 2025年4月1日 (国際出願日),
    国際公開番号 WO2025/220487 A1 (基礎出願:特願2024-067571号, 優先日: 2024年4月18日).
  3. Keita Tomochika, Takuya Kiyokawa, Tsukasa Ogasawara, Jun Takamatsu, and Ming Ding:
    ''Learning dataset creation method and device,''
    United States, Patent No. US11276194, 28.03.2019 (filing date).
  4. Keita Tomochika, Takuya Kiyokawa, Tsukasa Ogasawara, Jun Takamatsu, and Ming Ding:
    ''Learning dataset creation method and device,''
    China, Publication No. CN111937034, 28.03.2019 (filing date).
  5. 友近 圭汰, 清川 拓哉, 小笠原 司, 高松 淳, 丁 明:
    ''学習データセット作製方法及び装置,''
    特許第7083189号, 28.03.2019(出願日).
  6. 友近 圭汰, 清川 拓哉, 小笠原 司, 高松 淳, 丁 明:
    ''学習データセット作製方法、並びに、物体認識及び位置姿勢推定方法,''
    特許第6474179号, 27.07.2018(出願日).

Grants and Research Projects (Principal Investigator)

14
  1. Oct. 2026 - Sept. 2027, Research Grant 2026 [Grant A], Nagamori Foundation Certificate
    ''Morphological Optimization of Modular Manipulation Robots Inspired by Biological Musculoskeletal Arrangements''
  2. Oct. 2026 - Sept. 2029, LOTUS Programme (ASPIRE), Japan Science and Technology Agency (JST)
    ''Safety-Aware World-Model-Based Non-Destructive Multi-Arm Robotic Disassembly''
  3. Aug. 2026 - Nov. 2030, Moonshot Research and Development Program, Moonshot Goal 3,
    Japan Science and Technology Agency (JST)

    ''Integrated Research and Development of Humanoids Capable of Operating in Challenging Environments''
  4. Apr. 2026 - Mar. 2027, The Research Grant, The Okawa Foundation for Information and Telecommunications
    ''Proof of Concept of Microfactory with Intelligent Space and Modular Robots''
  5. Apr. 2025 - Mar. 2028, Grant-in-Aid for Early-Career Scientists, Japan Society for the Promotion of Science (JSPS)
    ''Acquisition of Self-Reconfiguration Behavior Patterns of Working Intelligent Robots with Flexible Bodies''
  6. Apr. 2023 - Mar. 2028, Research Commissioned by NEDO and Panasonic Holdings Corporation
    Principal investigator at The University of Osaka,
    ''Development of Basic Technology to Process E-Waste for an Advanced Resource Circulation System''

    ''Introduction to this project on The University of Osaka website's SDG efforts''
  7. Apr. 2025 - Feb. 2026, Collaborative Program for Fostering Next-Generation Researchers:
    Interdisciplinary Fusion Research Project through the Cooperation of Three Professions, The University of Osaka

    ''Design and Implementation of Self-Reconfigurable Intelligent Robots Based on an Evolutionary Biology Perspective''
  8. Aug. 2024, Suzuki Foundation, Grants for Overseas Training
    For participation at IEEE International Conference on Automation Science and Engineering 2024 (CASE2024)
  9. Oct. 2023 - Mar. 2024, Long-Term Overseas Research Support, The Telecommunications Advancement Foundations
    Research Stay at German Aerospace Center (DLR)
  10. Oct. 2023 - Mar. 2024, Overseas Dispatch Program for Young Researchers,
    Multidisciplinary Research Laboratory System for Future Developments, Graduate School of Engineering Science, The University of Osaka

    Research Stay at German Aerospace Center (DLR)
  11. Oct. 2023 - Mar. 2024, Overseas Research Support Program for Young Researchers from Global Affairs, The University of Osaka
    Research Stay at German Aerospace Center (DLR)
  12. Apr. 2021 - Mar. 2022, Research Grant for Young Researchers from NAIST Foundation
    ''Agile Reconfigurable Robotic Assembly System''
  13. Apr. 2020 - Mar. 2025, Research Commissioned by NEDO and AIST
    Principal investigator at The University of Osaka,
    ''Innovative Plastic Resource Recycling Process Technology Development''
  14. Apr. 2019, The NEC C&C Foundation, Grant for Researchers Attending International Conferences
    For participation at IEEE International Conference on Robotics and Automation 2019 (ICRA2019)

Personal Honors and Awards

12
  1. Sept. 2026, Young Investigation Excellence Award - The Robotics Society of Japan (RSJ) Certificate Medal
    Takuya Kiyokawa:

    ``Integrated Planning for Non-Destructive Disassembly Based on Disassemblability Derived Solely from Design Models''
  2. June 2026, Best Pitch Presentation, Circular Robotics: Designing Sustainable Autonomy for a Finite World (ICRA 2026 Workshop) Certificate
    Takuya Kiyokawa:

    ``Towards Design for Robotics: Disassemblability-Driven Non-Destructive Disassembly of Home Appliances''
  3. Jan. 2026, Best Presentation Award - The Society of Instrument and Control Engineers (SICE) Certificate
    Takuya Kiyokawa, Takuya Iwamoto, Yuto Noguchi, Nobukazu Takeda, and Kensuke Harada:

    ``Path Planning to Minimize Joint Loads for Heavy Object Manipulation in Complex Environments''
  4. Jan. 2026, Best Presentation Award - The Society of Instrument and Control Engineers (SICE) Certificate
    Takuya Kiyokawa, Tomoki Ishikura, Shingo Hamada, Genichiro Matsuda, Kensuke Harada:

    ``Component Influence Estimation via Robotic Disassembly Planning''
  5. Aug. 2025, Peter Luh Memorial Best Paper Award for Young Researcher - Finalist, IEEE Robotics and Automation Society Certificate
    Takuya Kiyokawa:

    ``Cooking Task Planning using LLM and Verified by Graph Network''
  6. Feb. 2025, Funai Information Technology Award for Young Researchers, The Funai Foundation Certificate Shield
    Takuya Kiyokawa:

    ``Study on Manipulation Planning by Intelligent Robots Using Design Information''
  7. Jan. 2025, SICE International Young Authors Award (SIYA), SICE Certificate
    Takuya Kiyokawa:

    ``Self-Supervised Learning of Grasping Arbitrary Objects On-the-Move''
  8. Nov. 2024, Σ Global Engineering Science Award, The University of Osaka Shield
    Takuya Kiyokawa:

    ``CAD-Informed Uncertainty-Aware Sequence and Motion Planning for Robotic Assembly''
  9. Mar. 2022, Telecommunication System Technology Student Award Certificate
    Takuya Kiyokawa, Keita Tomochika, Jun Takamatsu, and Tsukasa Ogasawara:

    ``Fully Automated Annotation With Noise-Masked Visual Markers for Deep-Learning-Based Object Detection,'' IEEE, Robotics and Automation Letters, April, 2019.
  10. June 2021, IEEE RAS Japan Joint Chapter Young Award, ICRA2021 Certificate
    Takuya Kiyokawa, Tatsuya Sakuma, Jun Takamatsu, and Tsukasa Ogasawara:

    ``Soft-Jig-Driven Assembly Operations''
  11. Nov. 2019, Special Award, Technical Academy Research Presentation in IIFES Certificate
    Takuya Kiyokawa, Jun Takamatsu, and Tsukasa Ogasawara:
    ``A Technology to Quickly Collect Dataset Using a Robot for Object Detection AI''
  12. May 2019, Certified as Super Creator by METI and IPA of Japan, MITOU program 2018 Certificate
    ``A Framework for Quickly Deploying Image Recognition AI''
    There are only 327 super creators in Japan from 2000 to 2019

Awards for Co-authored Papers

13
  1. 5th Young Presentation Award, Robotics Society of Japan, 2026 (RSJ2025)
    Awards ceremony: September 3, 2026
    Authors: Vitor Hideyo Isume, Takuya Kiyokawa, Natsuki Yamanobe, Yukiyasu Domae, Weiwei Wan, Kensuke Harada
    Recipient: Isume Vitor Hideyo (The University of Osaka)
    ``Craft Assembly Plans in Combination with LLMs and Physics Simulation''
    43rd Annual Conference of the Robotics Society of Japan (RSJ2025), 2F2-03
  2. International Session Best Presentation Award - Finalist, RSJ2025
    Authors: Zhenting Wang, Takuya Kiyokawa, Natsuki Yamanobe, Weiwei Wan, Kensuke Harada
    Finalist: Zhenting Wang
    ``Task Allocation for Human-Robot Collaborative Assembly by Predicting Human-Related Complexity''
  3. IEEE RAS Japan Joint Chapter Young Award, CASE2025
    Authors: Radwa Ali, Zhengtao Hu, Takuya Kiyokawa, Weiwei Wan, Tatsushi Nishi, Kensuke Harada
    Recipient: Radwa Ali
    ``Task and Grasp Constrained 3D Robotic Work-Cell Layout Planning''
  4. IEEE RAS Japan Joint Chapter Young Award, ICRA2025
    Authors: Vitor Hideyo Isume, Takuya Kiyokawa, Natsuki Yamanobe, Yukiyasu Domae, Weiwei Wan, Kensuke Harada
    Recipient: Vitor Hideyo Isume
    ``Component Selection for Craft Assembly Tasks''
  5. Best Presentation Award, SI2024 (SICE)
    Authors: Ryunosuke Takebayashi, Takuya Kiyokawa, Kensuke Harada, Tomoki Ishikura, Naoya Miyaji, Genichiro Matsuda
    Recipient: Ryunosuke Takebayashi
    ``Shell-Type Soft Jig for Maintaining Object Posture during Disassembly'' (in Japanese)
  6. Best Presentation Award, SI2023 (SICE)
    Authors: Hiroki Hanai, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada
    Recipient: Hiroki Hanai
    ``Multi-Step Wrapping Operations Based on Learning Hybrid Position/Force Control'' (in Japanese)
  7. Best Presentation Award, SI2022 (SICE)
    Authors: Shusei Nagato, Tomohiro Motoda, Takao Nishi, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada
    Recipient: Shusei Nagato
    ``Dual-Arm Extraction Planning from Clutter Using Object State Transition Prediction'' (in Japanese)
  8. Best Presentation Award, SI2022 (SICE)
    Authors: Ryo Kitamura, Keisuke Koyama, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada
    Recipient: Ryo Kitamura
    ``Automatic Parameter Tuning for Vision-Sensorless Bin Picking'' (in Japanese)
  9. Best Presentation Award, SI2022 (SICE)
    Authors: Yuuga Nakamura, Weiwei Wan, Takuya Kiyokawa, Kensuke Harada
    Recipient: Yuuga Nakamura
    ``Generating Non-Prehensile Lifting Motions Using Reinforcement Learning'' (in Japanese)
  10. IEEE RAS Japan Joint Chapter Young Award, ICRA2022
    Authors: Hao Chen, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada
    Recipient: Hao Chen
    ``Category-Association Based Similarity Matching for Novel Object Pick-and-Place Task''
  11. Best Presentation Award, SI2021 (SICE)
    Authors: Kento Nakatsuru, Weiwei Wan, Takuya Kiyokawa, Keisuke Koyama, Kensuke Harada
    Recipient: Kento Nakatsuru
    ``Planning and Optimization of Mobile Manipulation of Large, Heavy Objects Using Environmental Contacts'' (in Japanese)
  12. International Session Best Presentation Award - Finalist, RSJ2021
    Authors: Hao Chen, Takuya Kiyokawa, Weiwei Wan, Kensuke Harada
    Finalist: Hao Chen
    ``Vision-Based Novel Object Grasping based on Object-Semantics Matching with Grasp Database''
  13. SICE International Young Authors Award (SIYA), SII2021
    Authors: Naoki Wake, Riku Arakawa, Iori Yanokura, Takuya Kiyokawa, Kazuhiro Sasabuchi, Jun Takamatsu, Katsushi Ikeuchi
    Recipient: Naoki Wake
    ``A Learning-from-Observation Framework: One-Shot Robot Teaching for Grasp-Manipulation-Release Household Operations''

International Exhibitions and Workshops

10
  1. Sept. 27 - Oct. 1, 2026, Late Breaking Results, IEEE/RSJ International Conference on Intelligent Robots and Systems
    Hao Chen, Masashi Yo, Takuya Kiyokawa, Weiwei Wan, and Kensuke Harada:

    ''One-Shot Grasp Adaptation for Tightly Packed Scenes via Prior-Guided Recovery of Affordance Regions''
  2. Oct. 1, 2026, Presentation at Workshop in IEEE/RSJ IROS2026 (Pittsburgh, PA, US)
    ''Creativity in Assembly ''
    Takuya Kiyokawa, Taichi Kato, and Kensuke Harada:
    ''Spatiotemporal Constraint-Aware Assistance Motion Generation and Replanning for Human–Robot Collaborative Manipulation Tasks'' (poster)
  3. Oct. 1, 2026, Organizing Workshop at IEEE IROS2026 (Pittsburgh, PA, US)
    ''Creativity in Assembly''
  4. Sept. 27, 2026, Presentation at Workshop in IEEE/RSJ IROS2026 (Pittsburgh, PA, US)
    ''Workshop on Future of Construction: Collaborative Robots for Fabrication, Manufacturing, and Inspection''
    Takuya Kiyokawa, Taichi Kato, and Kensuke Harada:
    ''Spatiotemporal Constraint-Aware Assistance Motion Generation and Replanning for Human–Robot Collaborative Manipulation Tasks'' (poster)
  5. June 1, 2026, Presentation at Workshop in IEEE ICRA2026 (Vienna, Austria)
    ''Circular Robotics: Designing Sustainable Autonomy for a Finite World''
    Takuya Kiyokawa:
    ''Towards Design-for-Robotics: Disassemblability-Driven Non-Destructive Disassembly of Home Appliances'' (pitch + poster)
  6. Oct. 21 - 23, 2025, Late Breaking Results Poster Session at IEEE IROS2025 (Hangzhou, China)
    Tatsuki Nishimura, Weiwei Wan, Takuya Kiyokawa, and Kensuke Harada:
    ''Learning Mobile Robot Pushing for Unwanted Object Removal in Dense Clutter'' (poster)
  7. Jan. 21, 2025, Organizing Workshop at IEEE/SICE SII2025 (Munich, Germany)
    ''Reconfigurable Manipulation Robots''
  8. May 14, 2024, Late Breaking Results Poster Session at IEEE ICRA2024 (Yokohama, Japan)
    Takuya Kiyokawa, Ismael Rodriguez, Korbinian Nottensteiner, Peter Lehner, Thomas Eiband, Maximo A. Roa, and Kensuke Harada:
    ''CAD-Informed Uncertainty-Aware Robotic Assembly Sequences'' (poster)
  9. June 14 - 18, 2021, IEEE RAS "Rehabilitation and Assistive Technologies based on Soft Robotics" (SofTech-Rehab) (Online) Certificate
    Participates selected based on the evaluation of their Curriculum Vitae and a motivational letter
  10. Jan. 7 - 10, 2020, Consumer Electronics Show (LAS VEGAS, US)
    ''Make AI Smarter, Quickly Sort Items'' (poster presentation and demonstration)

Japanese Exhibitions and Workshops

10
  1. Nov. 24 - 25, 2022, 2nd Challenge Expo (Tokyo) Poster
    ''Make Anyone's Recognition AI Smarter, Quickly!!'' (poster, presentation, demonstration)
  2. Nov. 27 - 29, 2019, Innovative Industry Fair for E x E Solutions (IIFES) (Tokyo) Poster
    ''A Technology to Quickly Collect Dataset Using a Robot for Object Detection AI'' (poster, presentation, demonstration)
  3. Oct. 31 - Nov. 2, 2019, Keihanna Info-Communication Fair (Kyoto)
    ''A Method for Quickly Generating Datasets to Improve Object Detectors'' (poster, demonstration)
  4. Aug. 30 - 31, 2018, Innovation Japan (Tokyo) Poster
    ''Make AI Smarter, Quickly Sort Items'' (poster, demonstration)
  5. Mar. 28, 2018, Keihanna Research Complex Seeds Presentation (Kyoto) No. 4
    ''Automated Training Data Collection for Product Recognition Systems'' (poster)
  6. Nov. 8 - 9, 2017, Business Encourage Fair (Osaka)
    ''A Framework for Quickly Deploying Product Recognition Systems'' (poster, oral presentation, demonstration)
  7. Oct. 26 - 28, 2017, Keihanna Info-Communication Fair (Kyoto)
    ''A Framework for Quickly Deploying Product Recognition Systems'' (poster, demonstration)
  8. Sept. 14, 2017, Keihanna Research Complex Seeds Presentation (Kyoto) No. 2
    ''Robot Picking System using Deep Learning'' (poster)
  9. Oct. 19 - 21, 2016, Japan Robot Week (Tokyo) YouTube
    ''Ball-Catching Robot'' (poster, demonstration)
  10. Oct. 13, 2016, Keihanna Business Messe 2016 (Kyoto) No.94
    ''Ball-Catching Robot'' (poster, demonstration)

Articles

3
  1. Oct. 2026, UNIVERSITY JOURNAL ONLINE
    ''As "Physical AI" gains attention, what is required to create robots that operate in the real world?''
  2. Sept. 2026, UNIVERSITY JOURNAL
    ''The Road to Reconfigurable Robots, Part 1: From Disassembling Discarded Home Appliances to Throwing and Grasping While Moving''
  3. Dec. 2021, TechXplore
    ''A soft jig that could enhance the performance of general-purpose assembly robots''

Invited Talks

9
  1. Sept. 1, 2026, SICE SI Division Manipulation Subcommittee
    ''Manipulation Autumn School 2026, "Integrated Planning for Long-horizon and Contact-rich Robot Manipulation"'' (Kanazawa University)
  2. Aug. 16, 2026, Symbiotic Intelligent Systems Research Center, The University of Osaka
    ''The 12th [At Home] The University of Osaka Robot Science Cafe: "Robot Limbs: Exploring the Skill of 'Grasping' and 'Walking'"'' (Zoom webinar, for high school students)
    Talk title: ''Is Manipulating Objects More Difficult Than Thinking?''
  3. Sept. 1, 2025, Invited talk, Microsoft Research Asia - Tokyo, Japan
    MSRA - Tokyo Talk Series, ''Model-Informed Approach to Long-Horizon, Contact-Rich Manipulation for Industrial Robots''
  4. Mar. 1, 2024, Invited talk, Agile Robots, Germany
    ''CAD-Based Robotic Assembly/Disassembly Planning''
  5. Feb. 21, 2024, Invited talk, Munich Institute of Robotics and Machine Intelligence (MIRMI), TUM, Germany
  6. Nov. 24, 2023, Invited talk, Technology Innovation Center, KUKA HQ, Germany
    ''CAD-Based Robotic Assembly/Disassembly Planning''
  7. Nov. 22, 2023, Invited talk, High Performance Humanoids Technologies, KIT, Germany
    ''CAD-Based Robotic Assembly/Disassembly Planning''
  8. Nov. 6, 2023, Invited talk, Cognitive Systems, TUM, Germany
    Doctoral Research Seminar, ``CAD-Based Robotic Assembly/Disassembly Planning''
  9. Aug. 3, 2022, Invited talk, The National Institute of Advanced Industrial Science and Technology (AIST), Japan
    SURE CONSORTIUM The 22nd Recycling Technology Seminar, ''Current Status and Challenges of Automated Sorting Robots for Densely Packed Mixed Industrial Waste''

Educational Activities and Societal Contributions

10
  1. Oct. 2025 - present, Lecturer, The University of Osaka
    ''Intelligent Systems Science Laboratory B (Robot Arm)'' for undergraduate students
  2. Apr. 2025 - present, Lecturer, Harada Laboratory, The University of Osaka
    ''Training on ROS2 programming'' for undergraduate students
  3. Apr. 2025 - present, Lecturer, Harada Laboratory, The University of Osaka
    ''Training on 3D CAD / 3D printer'' for undergraduate students
  4. Aug. 1, 2023 - present, Kumamoto Nichinichi Shimbun and Ministry of Economy, Trade and Industry (METI)
    ''Kumamoto MITOU Project IPPO / METI AKATSUKI Project'' (Local Young Human Resource Discovery and Development Support Project, Kumamoto, Japan)
    Project Manager (PM)
  5. Apr. 2023 - present, The University of Osaka
    ''Efforts to Realize Careful and Rapid Home Appliance Disassembly by Intelligent Robots for Circular Manufacturing'' (The University of Osaka x SDGs Website)
    Consultant, logistic support, investigator, report author
  6. Apr. 2024 - July 2024, Lecturer, The University of Osaka
    ''A Door to Academia (Intelligent Robotic System)'' for undergraduate students
  7. Apr. 2023 - July 2025, Lecturer, The University of Osaka
    ''Intelligent Systems Science Laboratory A (Feedback Control)'' for undergraduate students
  8. Dec. 2022 - Mar. 2023, Lecturer, The University of Osaka
    ''Information and Computer Exercises'' for undergraduate students
  9. May 9, 2022 - Nov. 24, 2022, DELL Technologies
    ''The 2nd Mid-sized Enterprise DX Acceleration Program''
    Lecturer, consultant, official expert
  10. Apr. 2021 - July 2021, Lecturer, The University of Osaka
    ''A Door to Academia (Intelligent Robotic System)'' for undergraduate students

Contact

Get in touch

Takuya Kiyokawa

Harada Laboratory
Graduate School of Engineering Science
The University of Osaka

kiyokawa.takuya.es@osaka-u.ac.jp

Address

1-3 Machikaneyama-cho, Toyonaka
Osaka 560-8531, Japan